BotverseX
BotverseX is my embodied AI workbench, connecting robots, teleoperation, data recording, training and deployment.
Owned product direction and business: defined target users and workflow boundaries, drove connect → teleoperate → record → train → deploy into one flow; implementation is delivered with the engineering team.
From plugging in to running on the robot.
The workbench puts these seven stages in one interface. Support differs by machine; some stages need a bridge or dedicated drivers.
- 01CONNECT
Connect
Serial, cameras, gripper, SDK version — confirm each one. When the first connection fails, it is rarely the model.
- 02CALIBRATE
Calibrate
Joint zeros, camera intrinsics and extrinsics, gripper travel. Skip it here and every later episode pays for it.
- 03TELEOPERATE
Teleoperate
Leader arm, keyboard or VR — get the motion working first. If it feels wrong, more data will not save it.
- 04RECORD
Record
Record episodes by task, keep the failures as well as the wins, and get naming and metadata right on the spot.
- 05TRAIN
Train
Run training locally or in the cloud; read the loss and the replays, not just the curve.
- 06DEPLOY
Deploy
Load the policy back onto the robot and validate it at low speed in an empty space before a real task.
- 07INFER
Infer
Run it on the real robot, log the failure cases, and go back to step one.
The long view is a hardware-focused companion to Hugging Face: one workbench where a maker can walk the same path — connect, calibrate, teleoperate, record, train, deploy, infer. Current work spans physical SO-101 and B601 robots as well as MicroDuck simulation. Support differs by platform; some workflows require a bridge or dedicated drivers.
The point cloud on the homepage is not a video: it is the robot body sampled from its URDF, streamed live and following the pointer. Change the machine and the body changes with it — no client install, feel first.
Experiments describe their actual environment and scope. Check the linked source for implementation details, license, current support and reproduction steps.
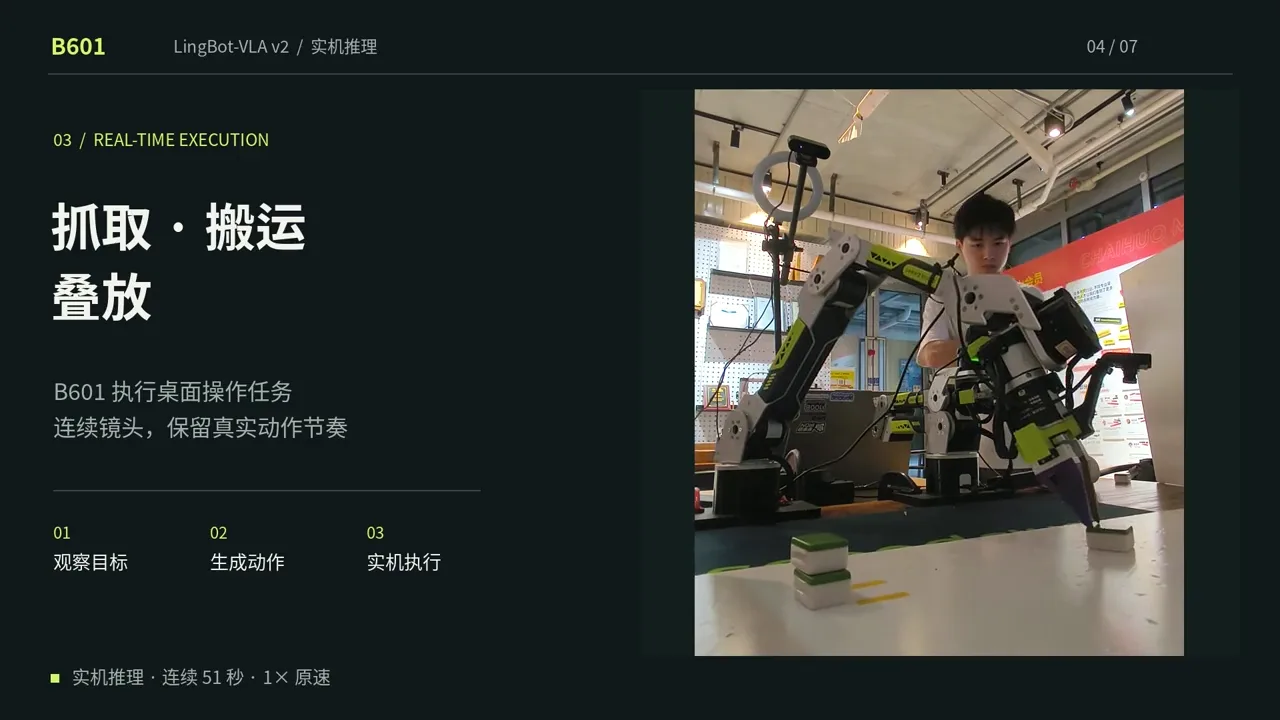 实机推理
B601 × LingBot-VLA v2
Bringing teleoperation demos, VLA inference and real dual arm manipulation together on the B601.
↗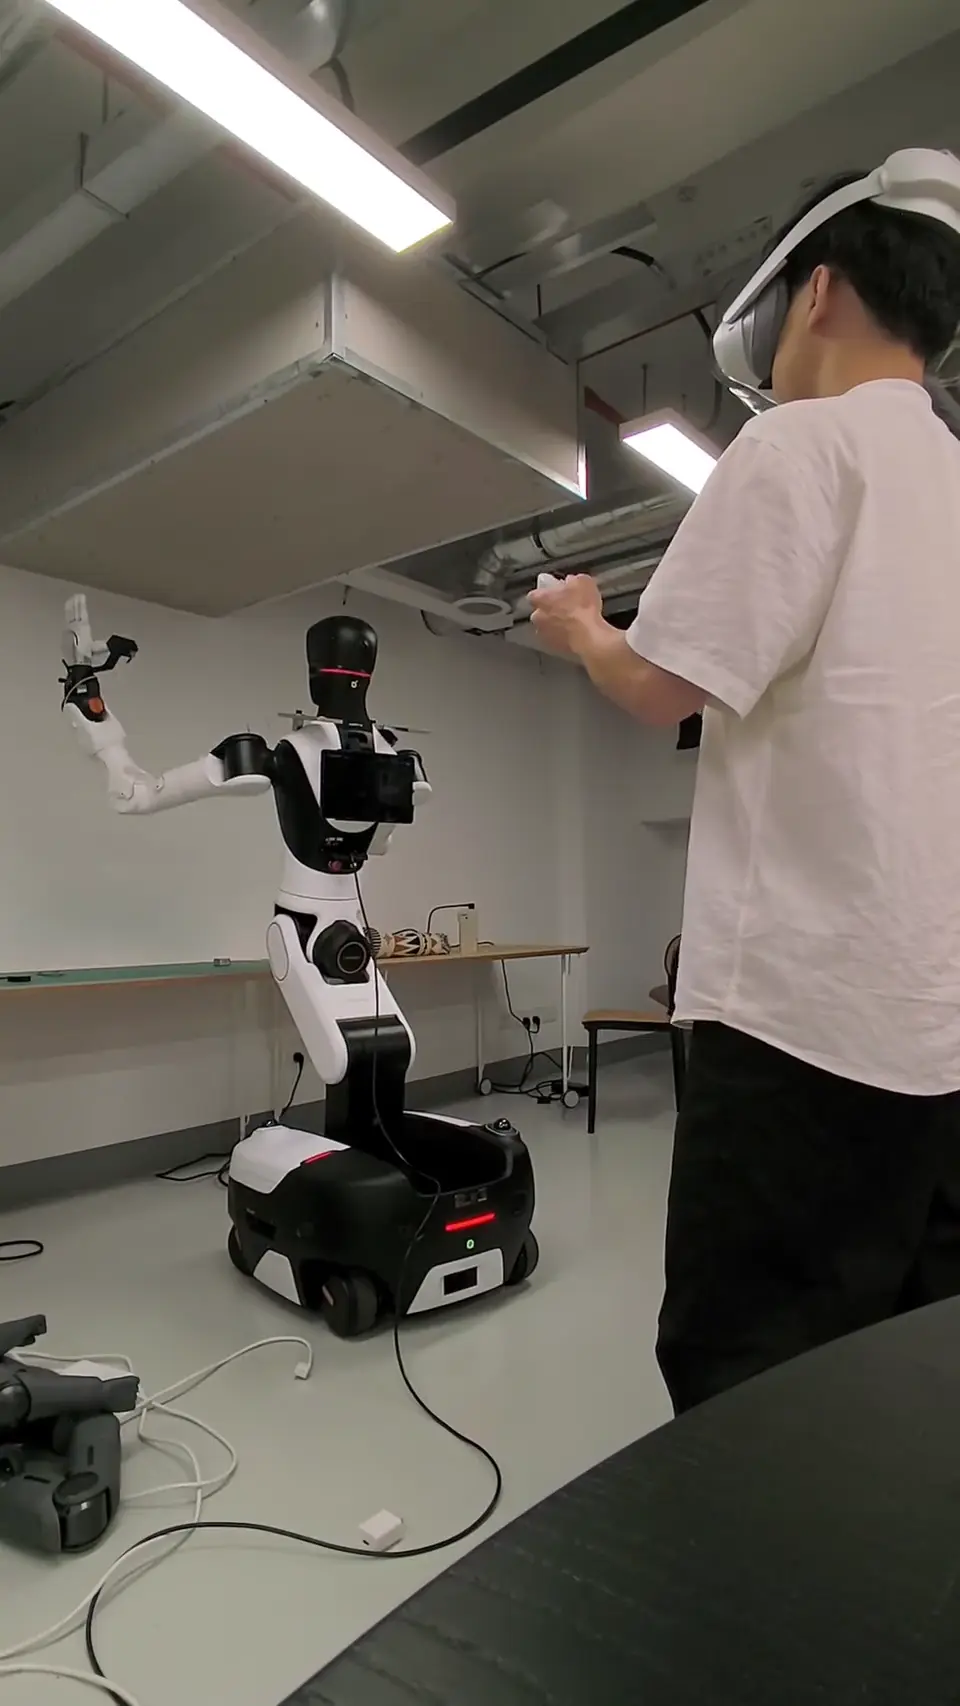 机器人平台 · 遥操作控制台
AGIBOT G2 / Lingxi X2
A local console for AGIBOT G2: a 3D skeleton and joint panel in the browser, and a headset view that pins five camera feeds in space with controller-driven arms.
↗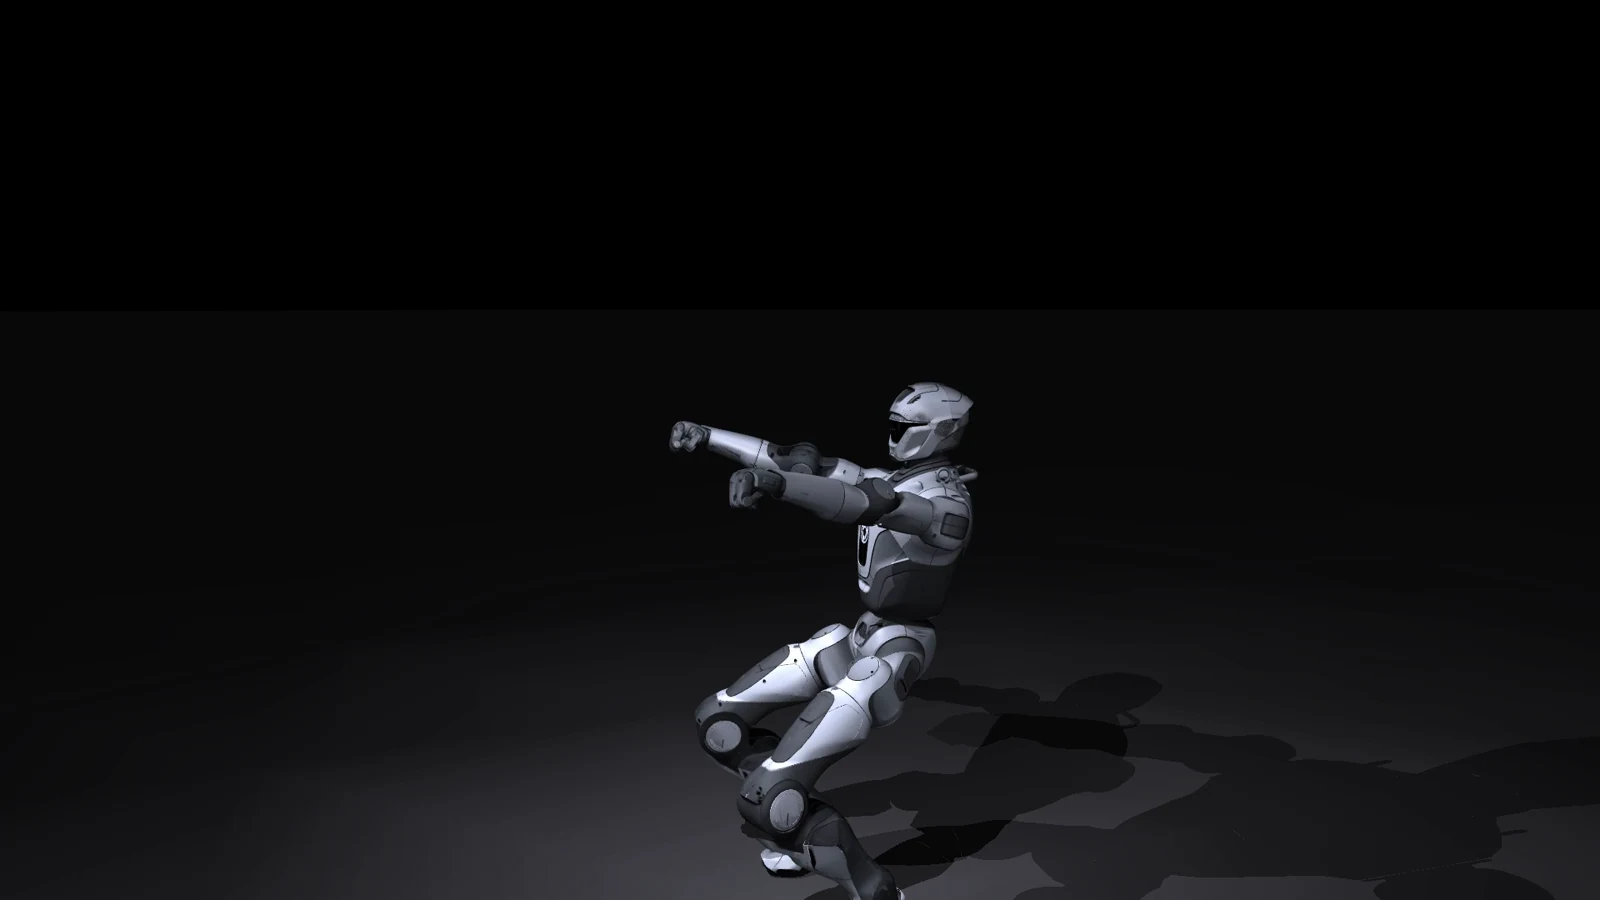 动作重定向 · 仿真
T800 / Backflip Retargeting
Moving G1 backflips from an open motion dataset onto the T800 humanoid: 1.227× leg-length retargeting, per-frame IK correction, and MuJoCo kinematic replay rendered at 50 fps. The RL branch failed to produce a policy.
↗