IDEASINTOREALITY.
Making AI
part of the physical world.
REAL ROBOT
Built at the bench.
Tested in the room.
Actual devices and work in progress. Clips play as you scroll.
Beyond the screen
is where life happens.
I lead product definition and business while working hands-on with a technical team on software, robot integration, model inference and hardware in Shenzhen. I like connecting software to the physical world: models that understand a real scene, robots that act, and tools people want to use.
From robot manipulation and MicroDuck to agent visibility and playful interactive experiments, this site tracks projects, open source code and field notes in progress. At MetaHub, I also work on enterprise AI products and delivery.
Read my story ↗IT
REAL®
Things, brought to life.
B601 ×
LingBot-VLA v2
Bringing demonstrations, model inference and a real robot together on the workbench.
↗T800 / Backflip Retargeting
Moving G1 backflips from an open motion dataset onto the T800 humanoid: 1.227× leg-length retargeting, per-frame IK correction, and MuJoCo kinematic replay rendered at 50 fps. The RL branch failed to produce a policy.
 03↗
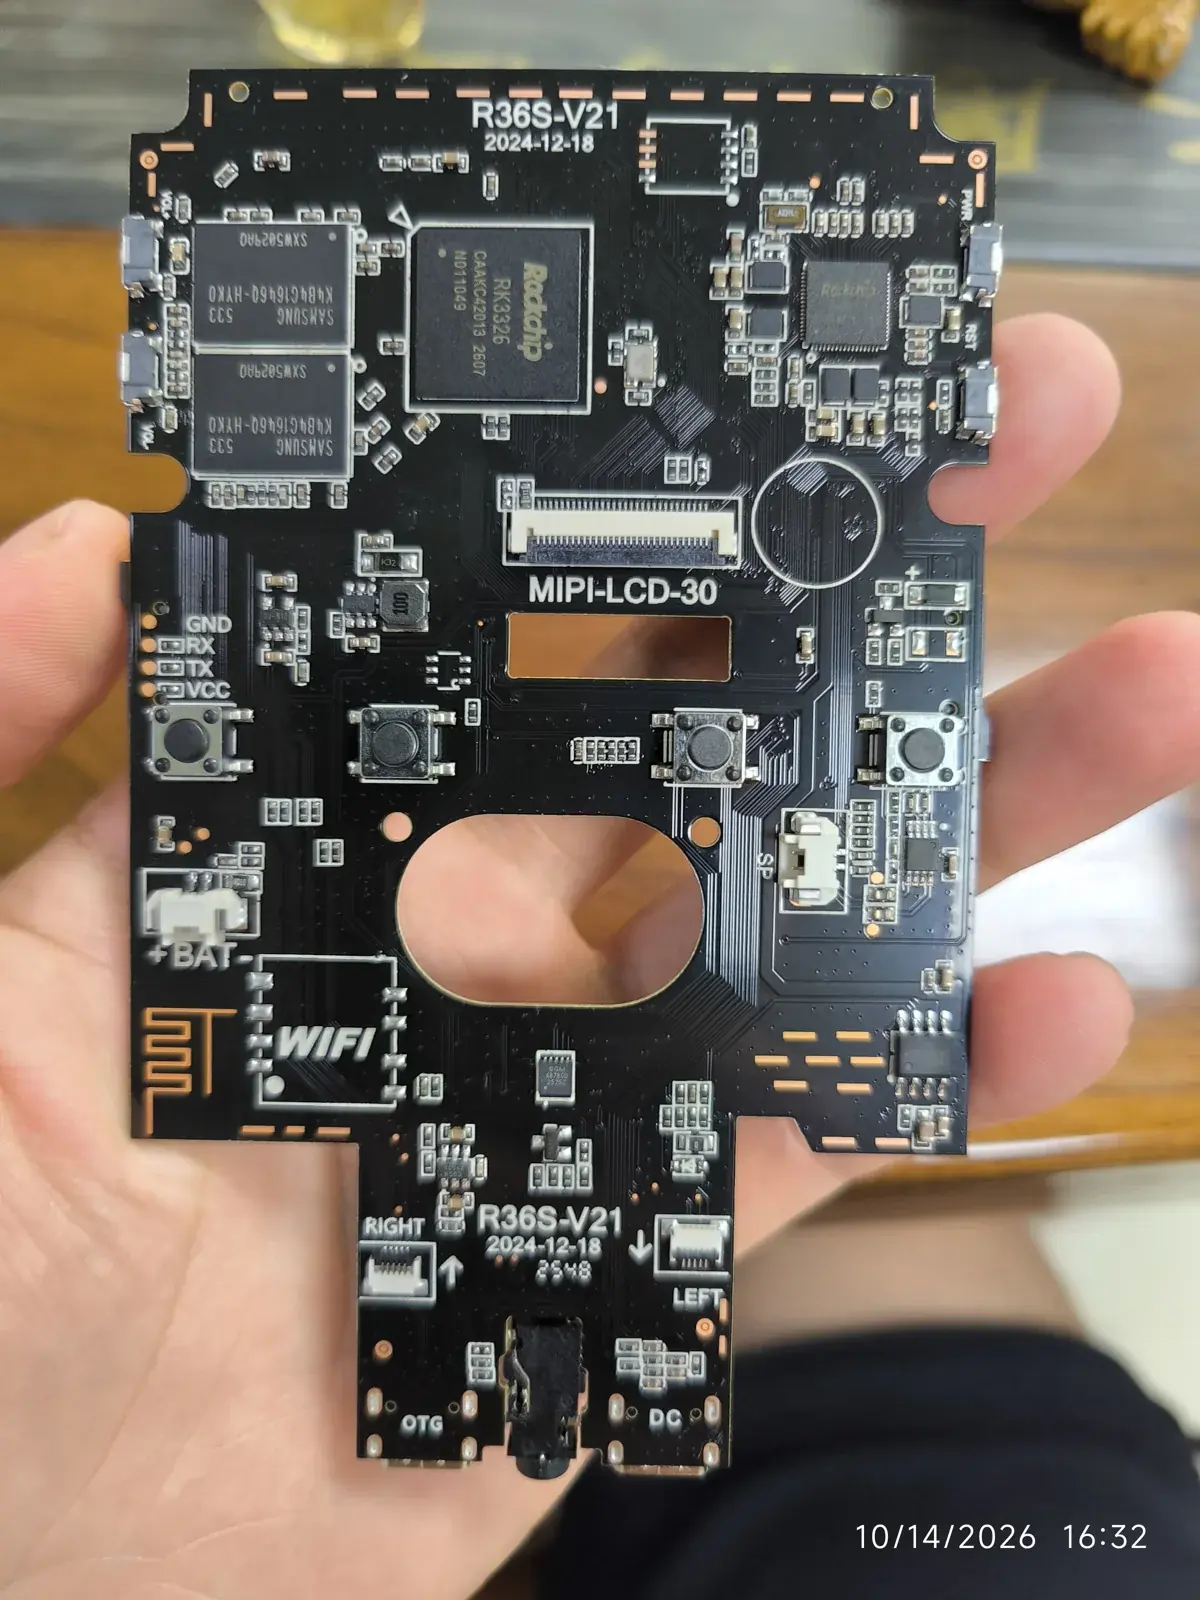
R36S / r36s.space
An independent R36S handheld shop and technical journal covering board identification, setup, SD cards and save files.
 04↗
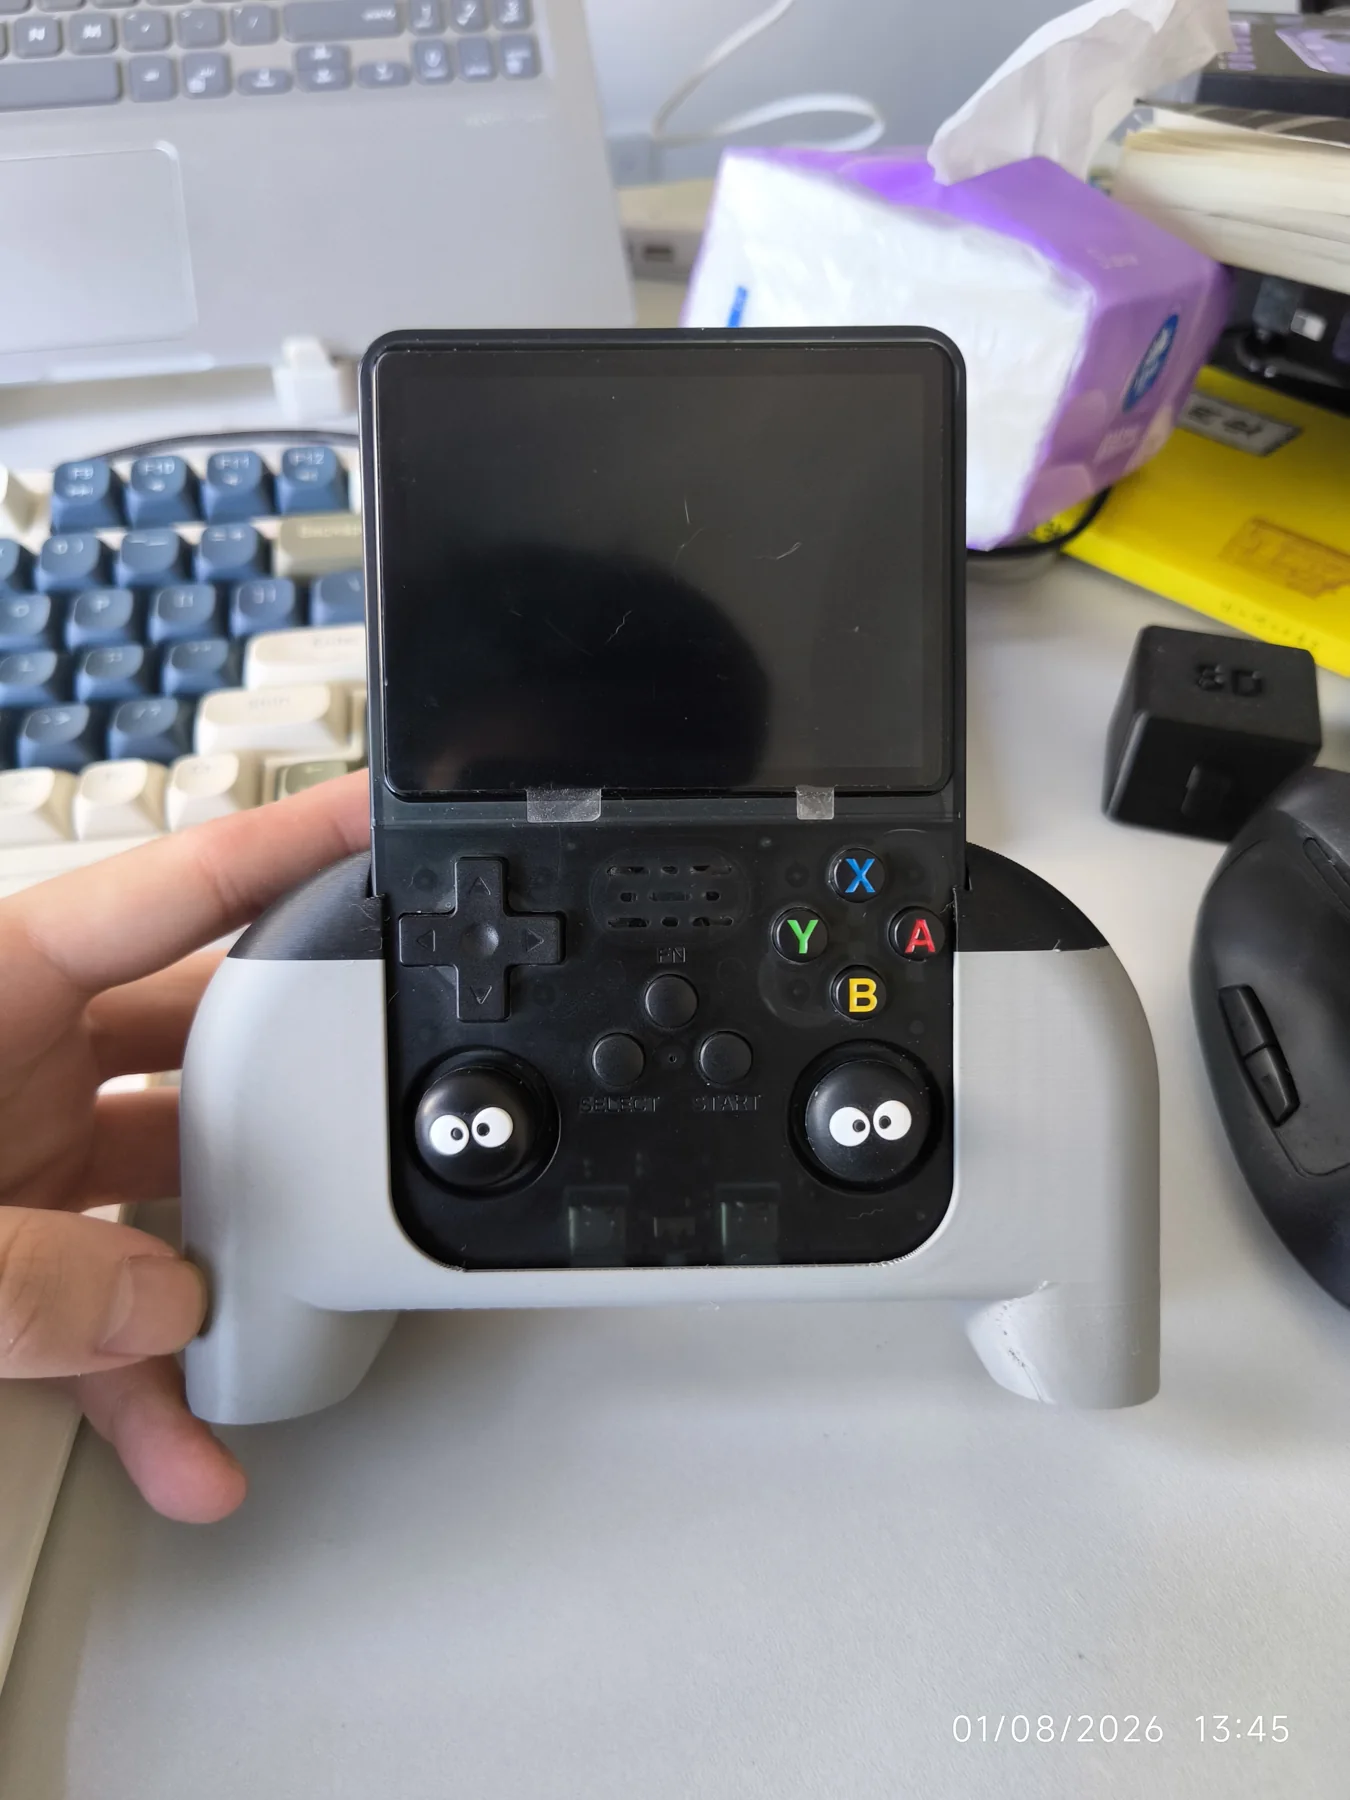
Handheld Tinkering
Two handhelds, four Linux builds and a 3D-printed grip: taking the R36S and RG353V apart until they feel like machines worth holding.
 05↗
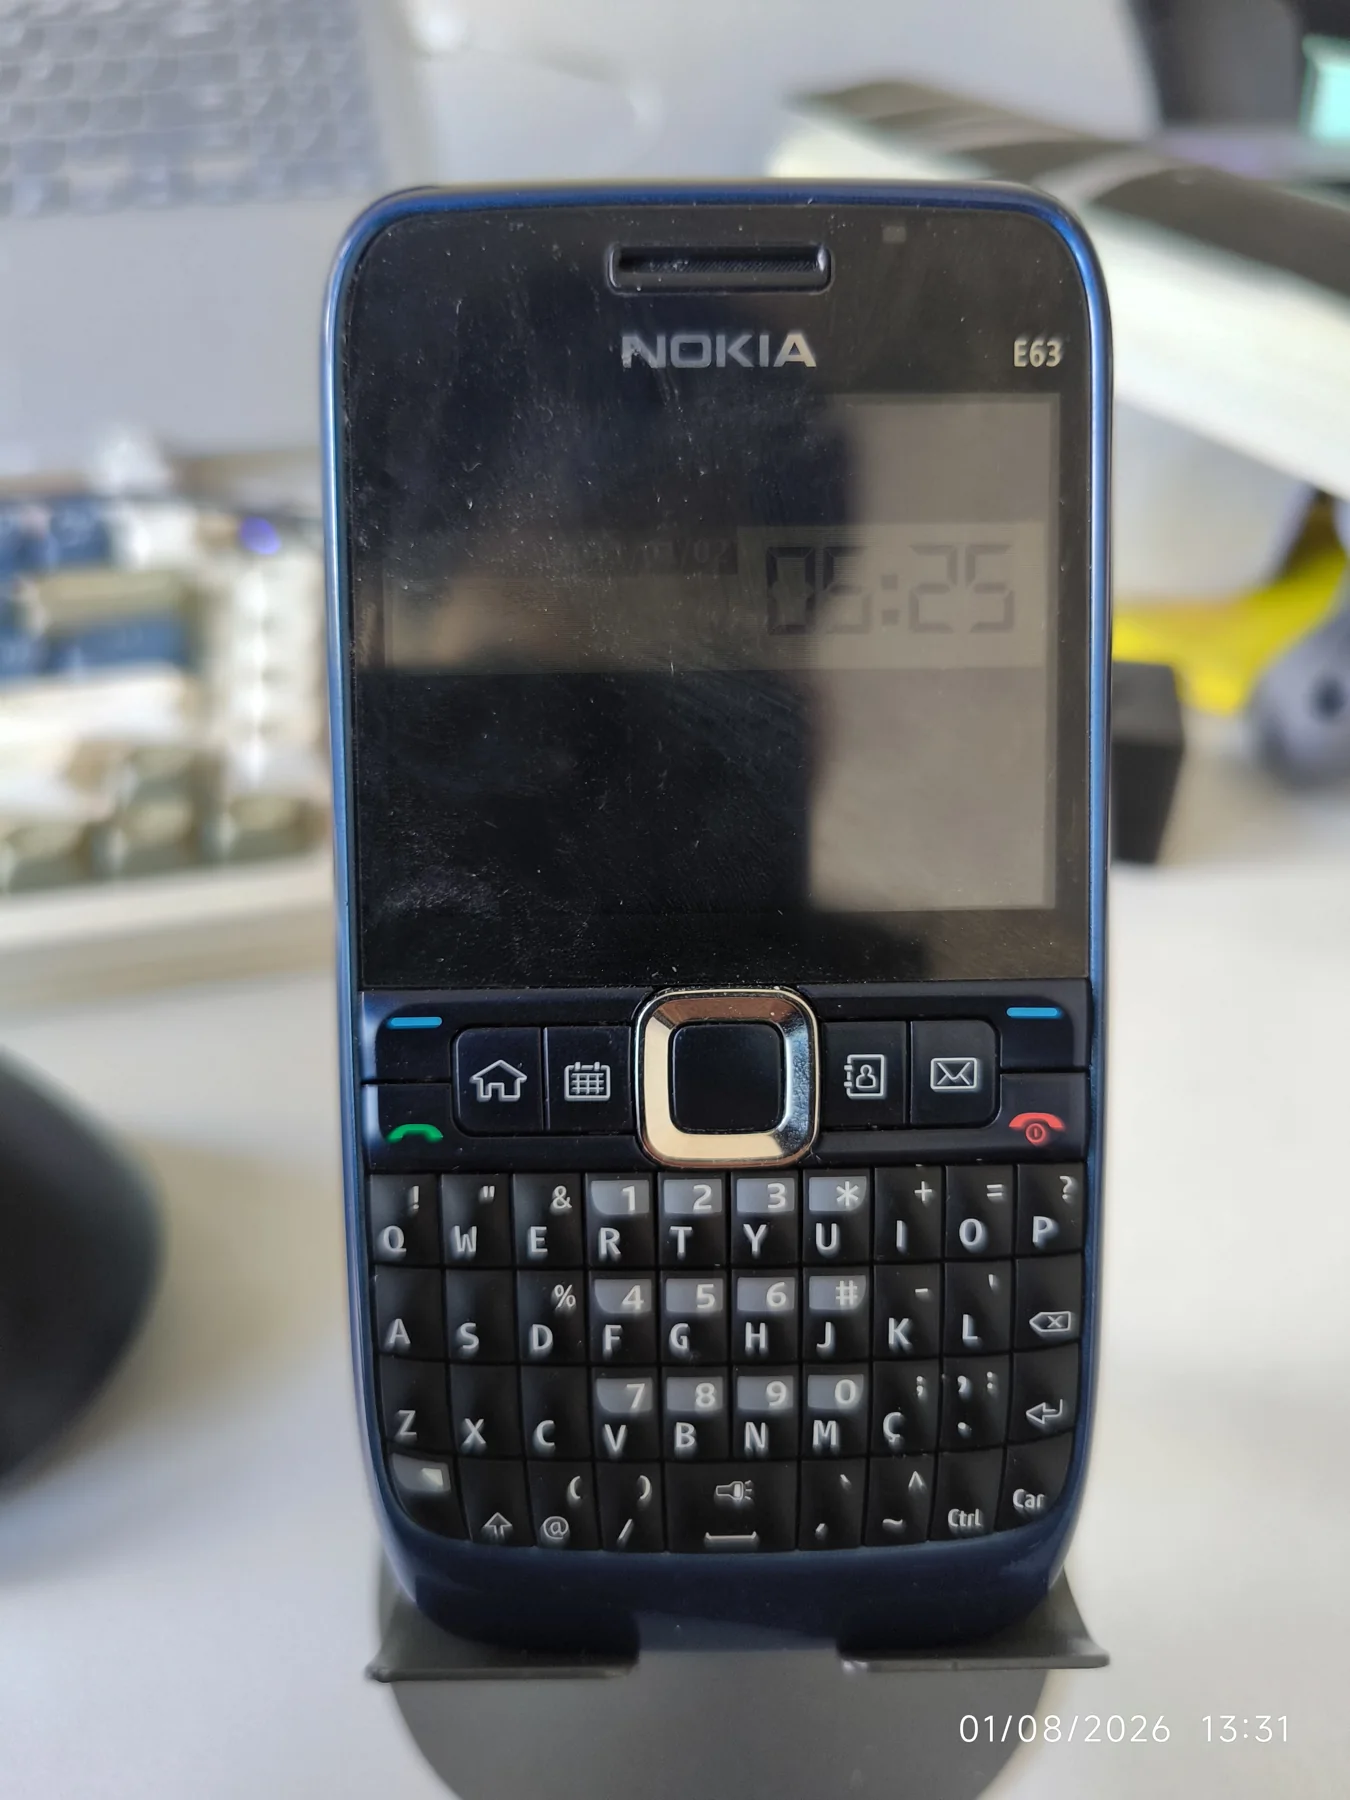
Classic Phones
A Nokia E63 and E72i back in daily use for TV, music and Bluetooth earphones — hardware from a decade ago that still does the job.
 06↗
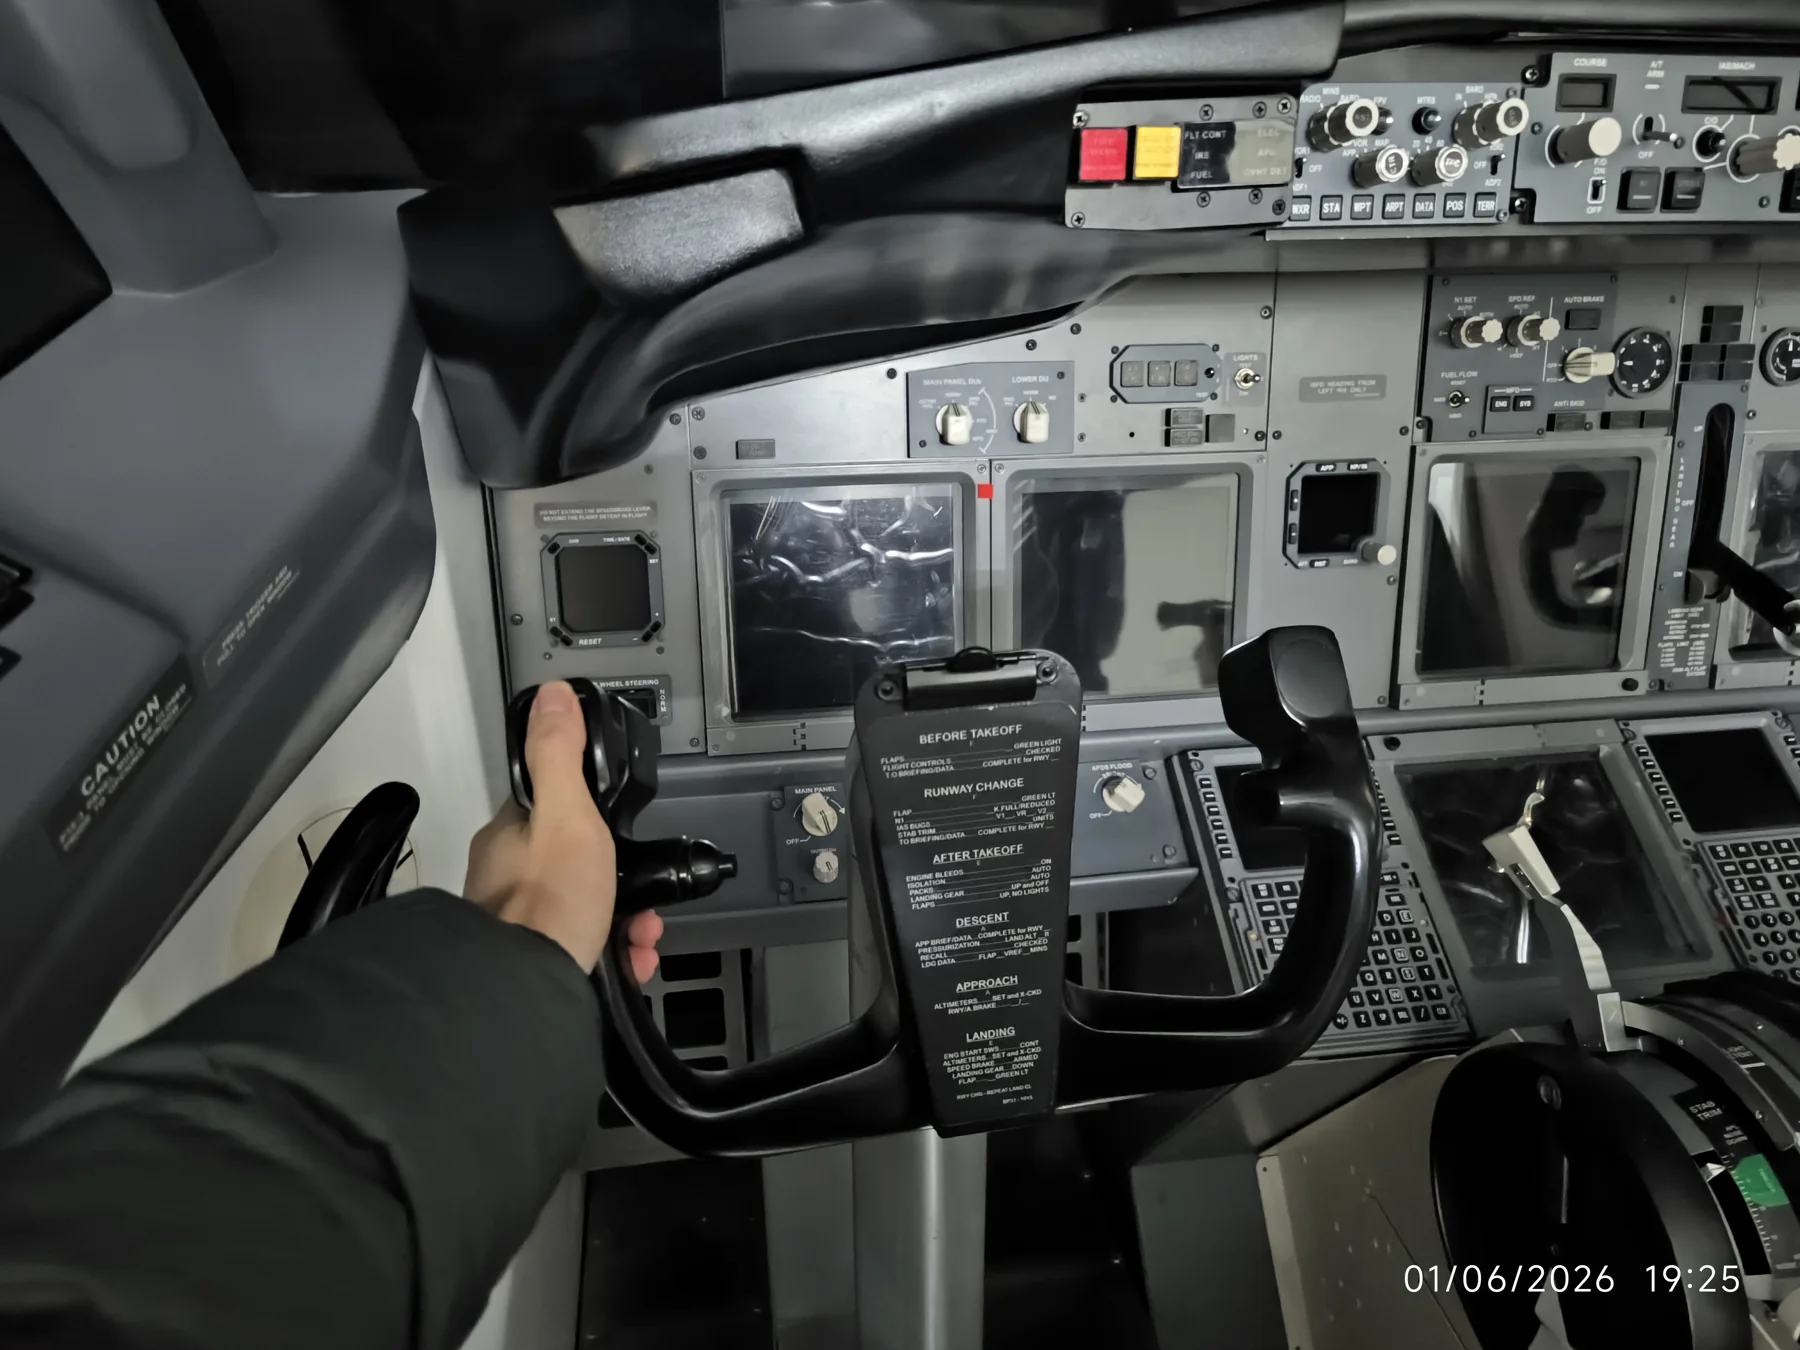
Flight Simulation
Time in a full-scale simulator cockpit, working through the checklists — plus the carrier models and COMAC keepsakes that keep aviation within reach.
BotverseX
BotverseX is my embodied AI workbench, connecting robots, teleoperation, data recording, training and deployment.
AGIBOT G2 / Lingxi X2
A local console for AGIBOT G2: a 3D skeleton and joint panel in the browser, and a headset view that pins five camera feeds in space with controller-driven arms.
JARVIS / Reachy Mini
A local JARVIS assistant bringing XTTS speech synthesis and Reachy Mini camera and motion controls together.
 10↗
Strata / Qwen3.8-Flash-Next
A 125B Qwen3.8-Flash-Next running on one RTX 5060 Ti: 16 GB VRAM, 64K context, 74–110 tok/s decode in a real session.
Make the idea
work in the real world.
I lead product definition and business, work hands-on through technical validation, and deliver alongside an engineering team. Open to custom AI and robotics projects with clear goals.
How I can help ↗Agents &
private deployment
Business workflows, knowledge systems and auditable integration.
02 / PHYSICAL AIRobotics &
VLA integration
Teleoperation, data collection, inference and real robot tests.
03 / CUSTOM BUILDProduct prototypes
& custom software
Connect product discovery, interaction design and engineering.
OPEN DATA, OPEN MODELS
Build here.
Share everywhere.
Nine public datasets and one public model, including experiments with B601, SO-101 and LeKiwi.
Browse datasets and models ↗More than lab time.
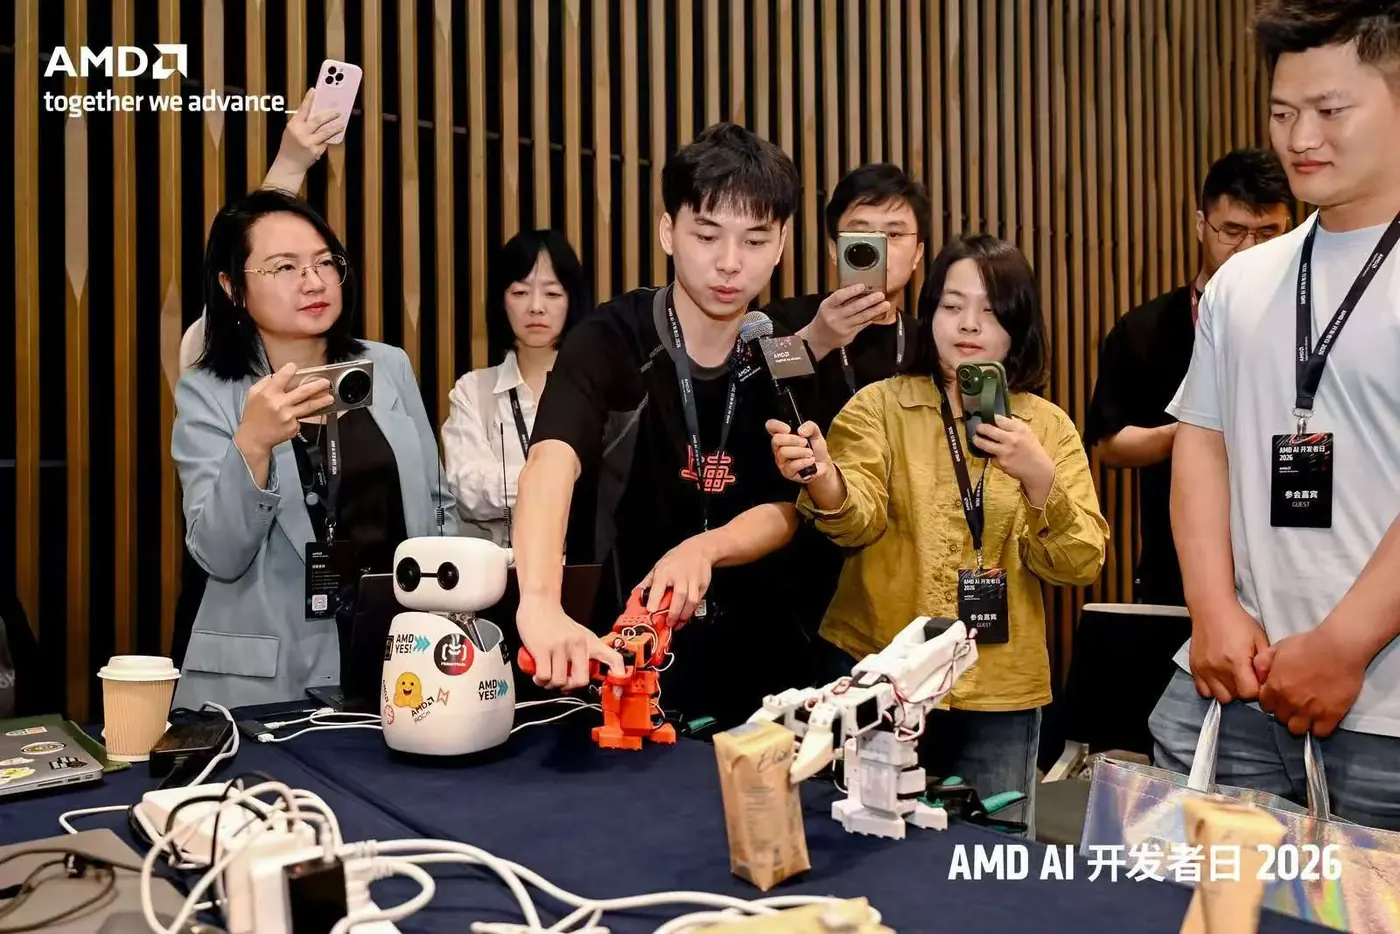 01 / BUILD IN PUBLIC
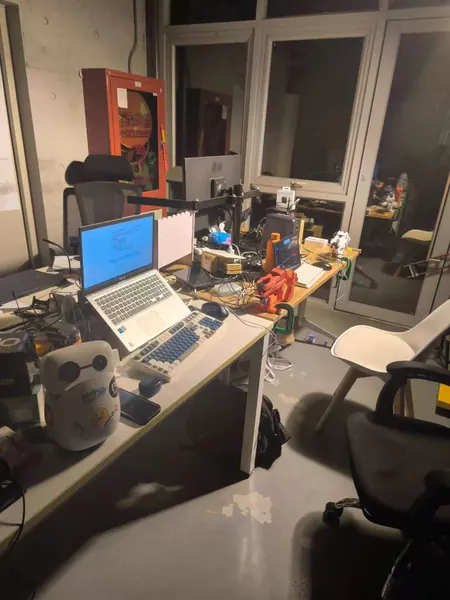
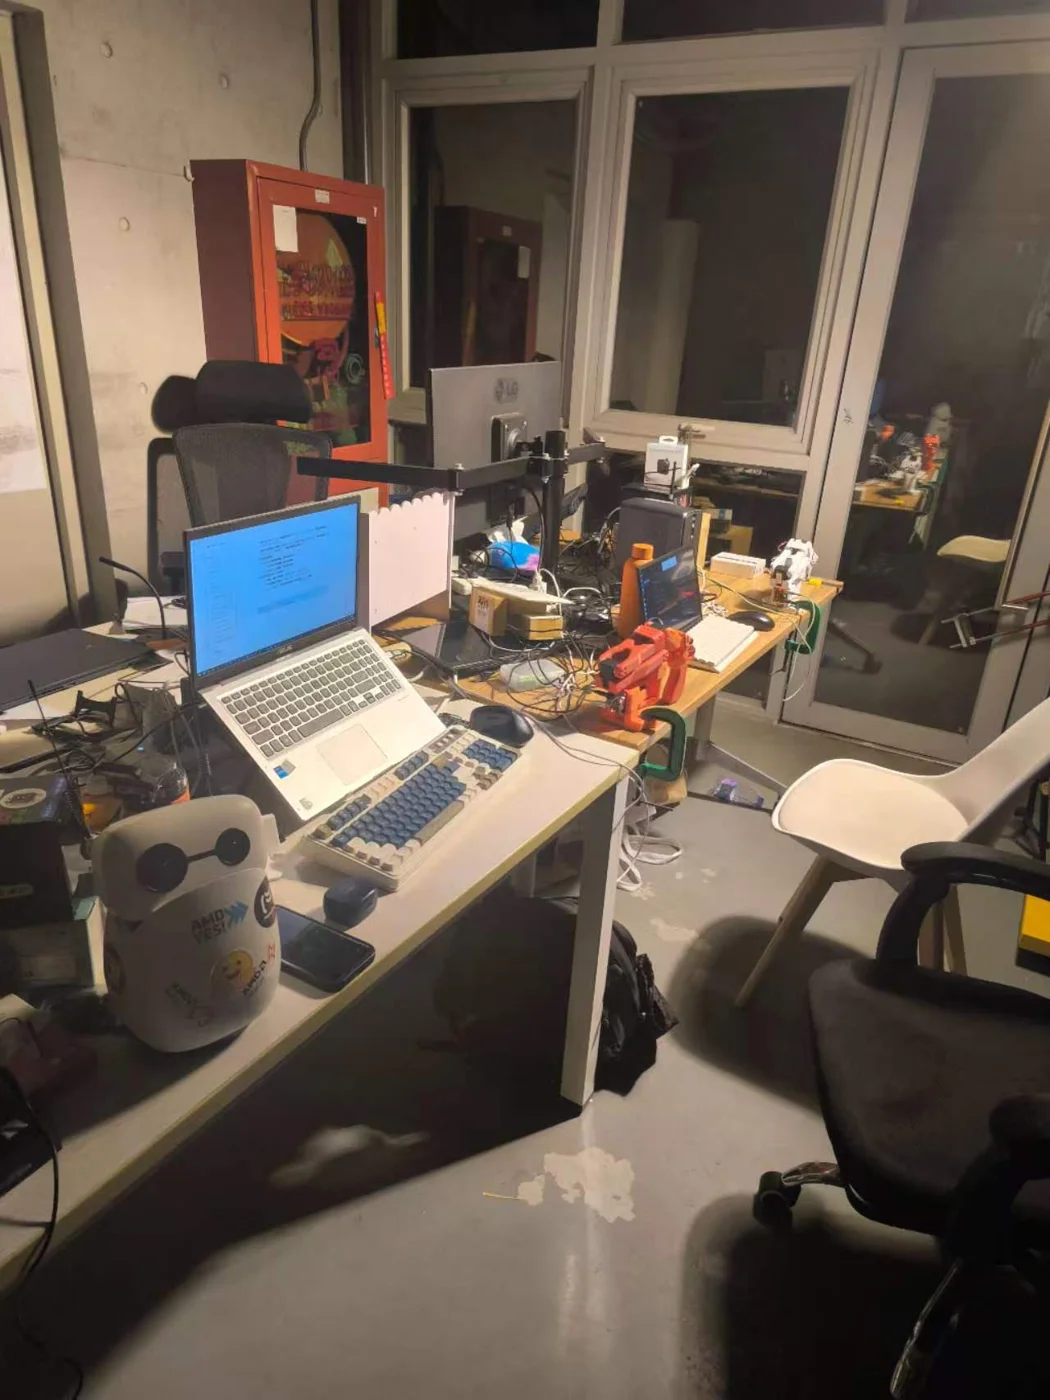 02 / AT THE WORKBENCH
Bring robotsMU SHANGHAI · CORE ORGANIZER
into the room.
MU SHENZHEN · NOV 2026
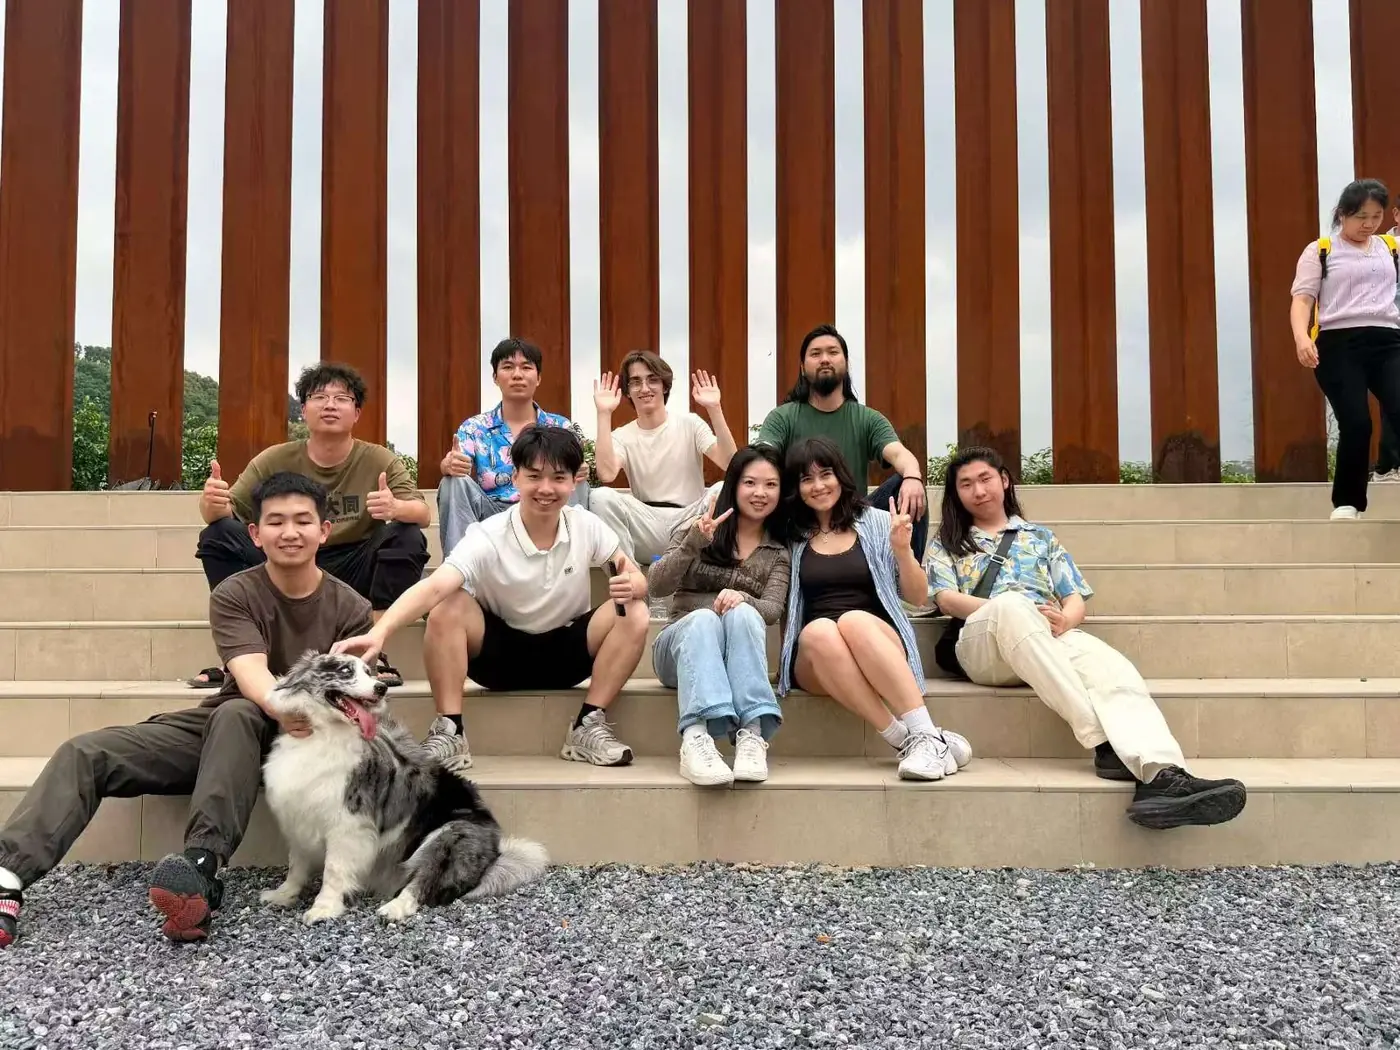 03 / MAKER COMMUNITY
Bring robotics
into the room.
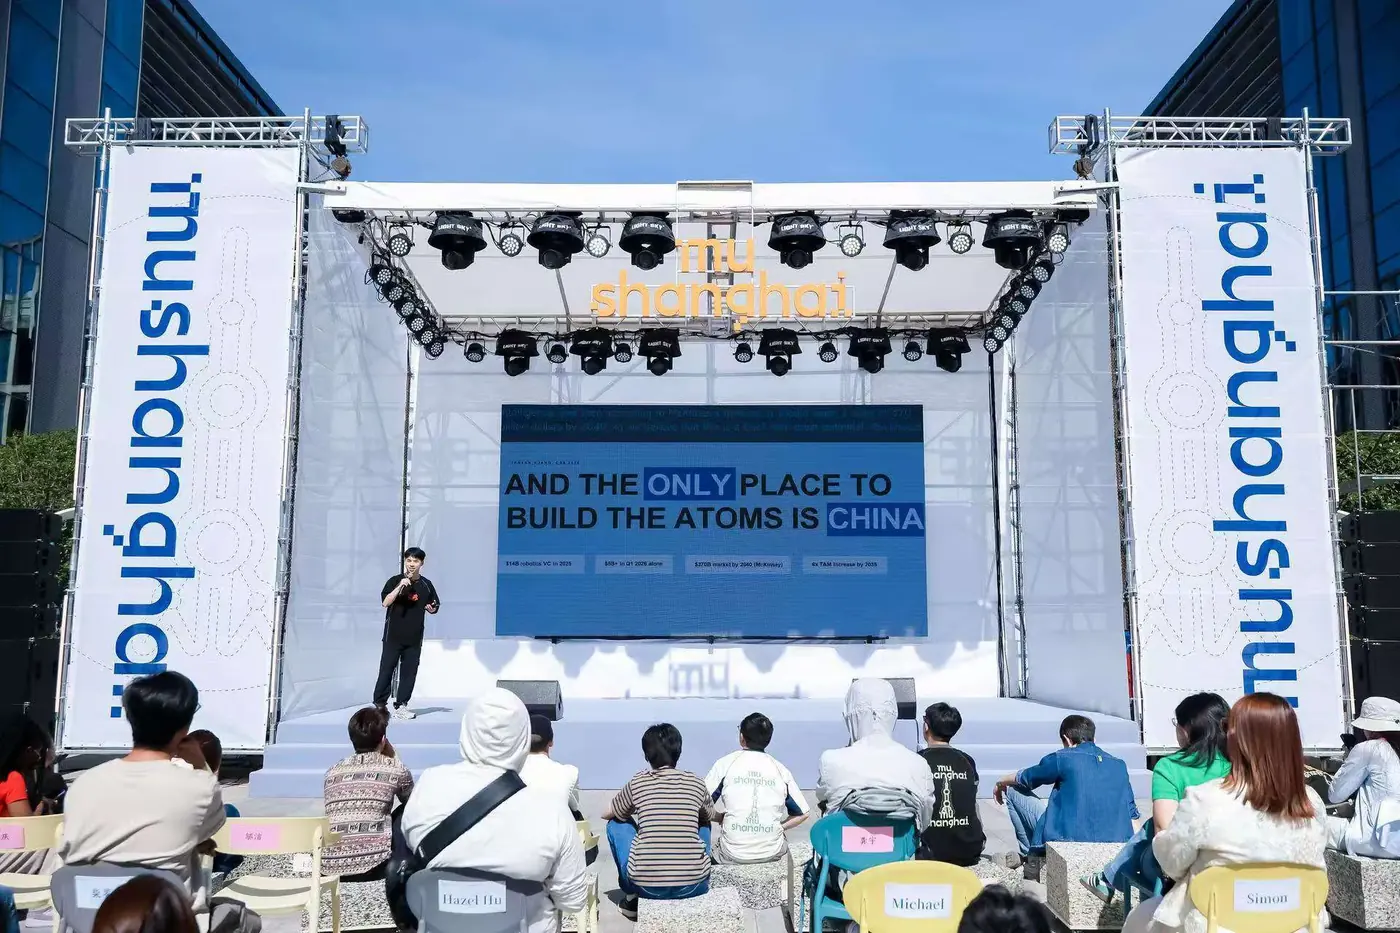
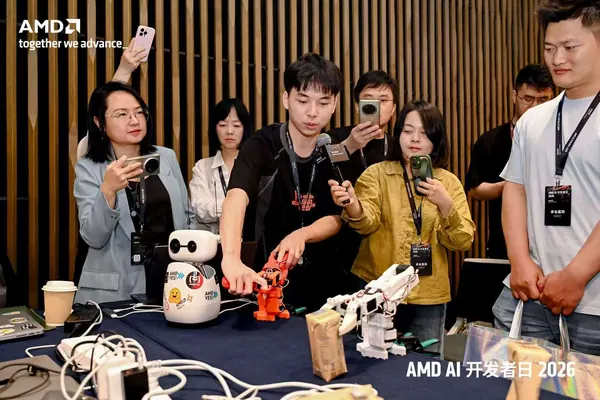
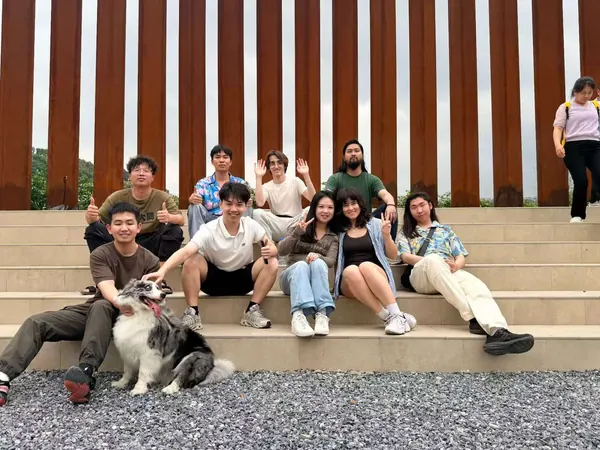
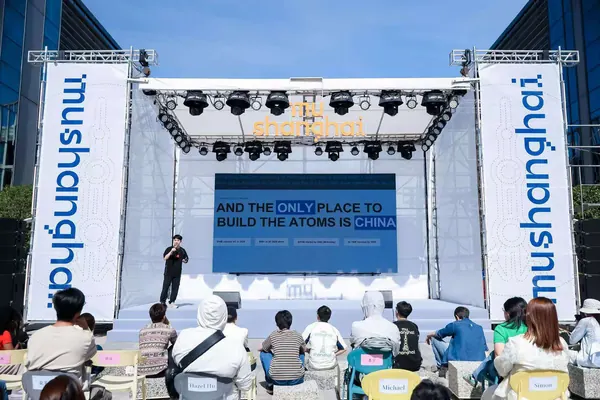
muShanghai Robotics Week
Core organizing team; hosted a hands-on AI hardware workshop.
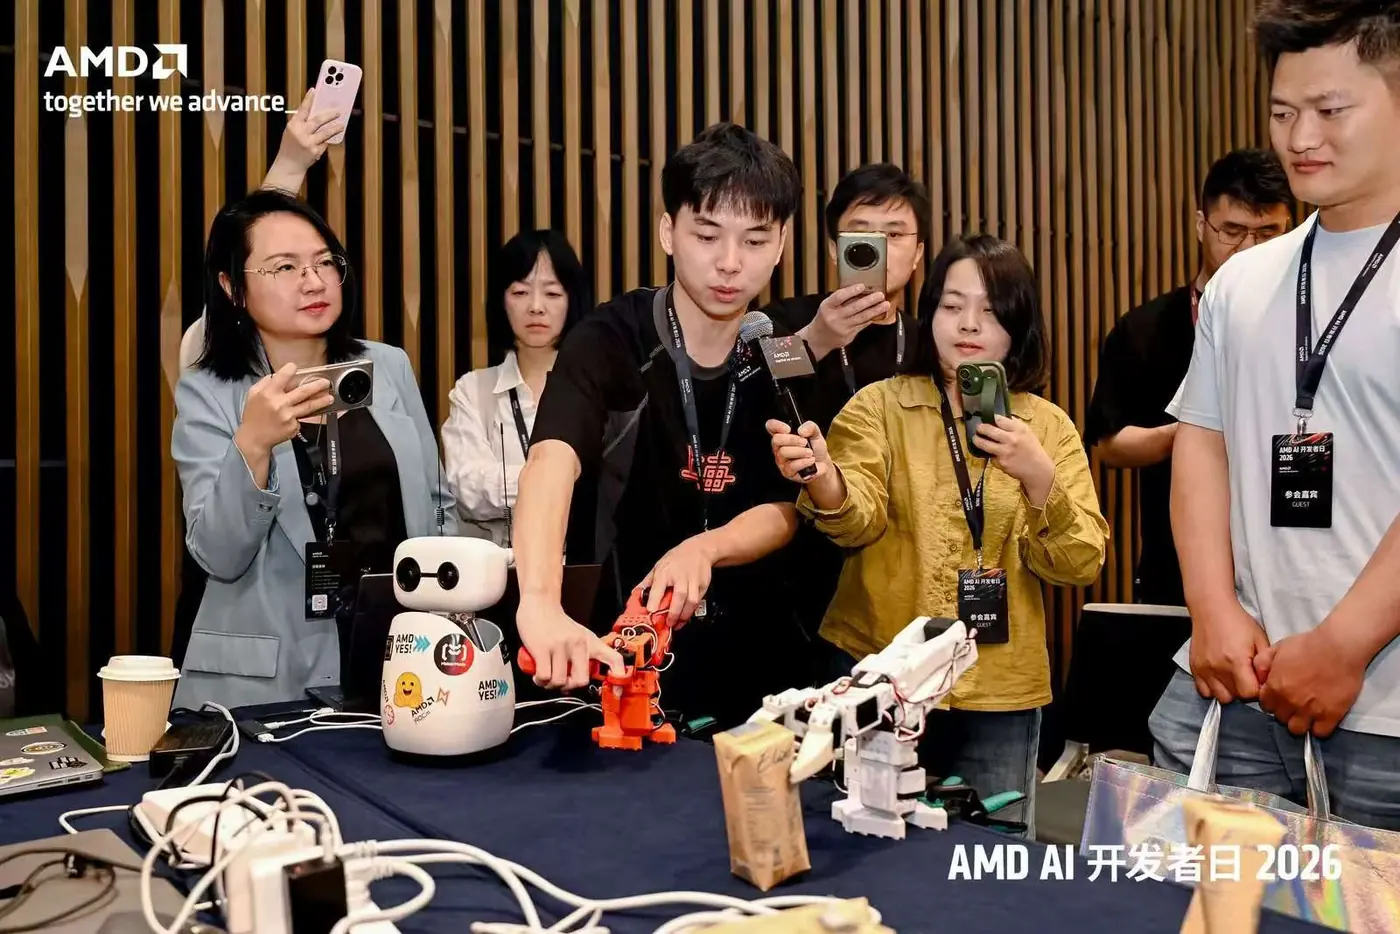
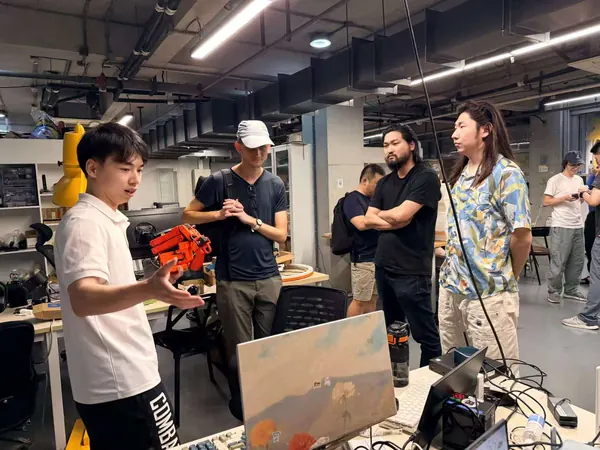
Robots in the room
Sharing dual arm robotics work with the maker community.
In progress / muShenzhen Robotics Week · November 2026
INTENTION↗