 01↗
Local experimentexperiments
A zero-shot voice cloning experiment with IndexTTS-2.5 on an RTX 5060 Ti. Jarvis speaks English, MOSS speaks Chinese: six new takes, six reference clips, and an online trial that reports whether the machine is on.
IndexTTS-2.5Voice cloningRTX 5060 Ti
02↗Roboticsrobotics
Bringing teleoperation demos, VLA inference and real dual arm manipulation together on the B601.
B601LingBot-VLA v2LeRobot
03↗Roboticsrobotics
Moving G1 backflips from an open motion dataset onto the T800 humanoid: 1.227× leg-length retargeting, per-frame IK correction, and MuJoCo kinematic replay rendered at 50 fps. The RL branch failed to produce a policy.
RetargetingIKMuJoCo
04↗Roboticsrobotics
From crouching to hopping: designing rewards that teach a small biped to jump in simulation.
PPOMuJoCoONNX
05↗Roboticsrobotics
The robot's stereo camera, telemetry, voice and motion control in one browser console — operating a Yuan Q1 humanoid in Shanghai from Shenzhen.
Web UIRobot ControlCamera
06↗Roboticsrobotics
BotverseX is my embodied AI workbench, connecting robots, teleoperation, data recording, training and deployment.
BotverseXPhysical AILeRobot
07↗Experimentsexperiments
Reconstructing a makerspace scene and exploring camera views and browsable 3D environments.
3D ReconstructionSpatialExperiment
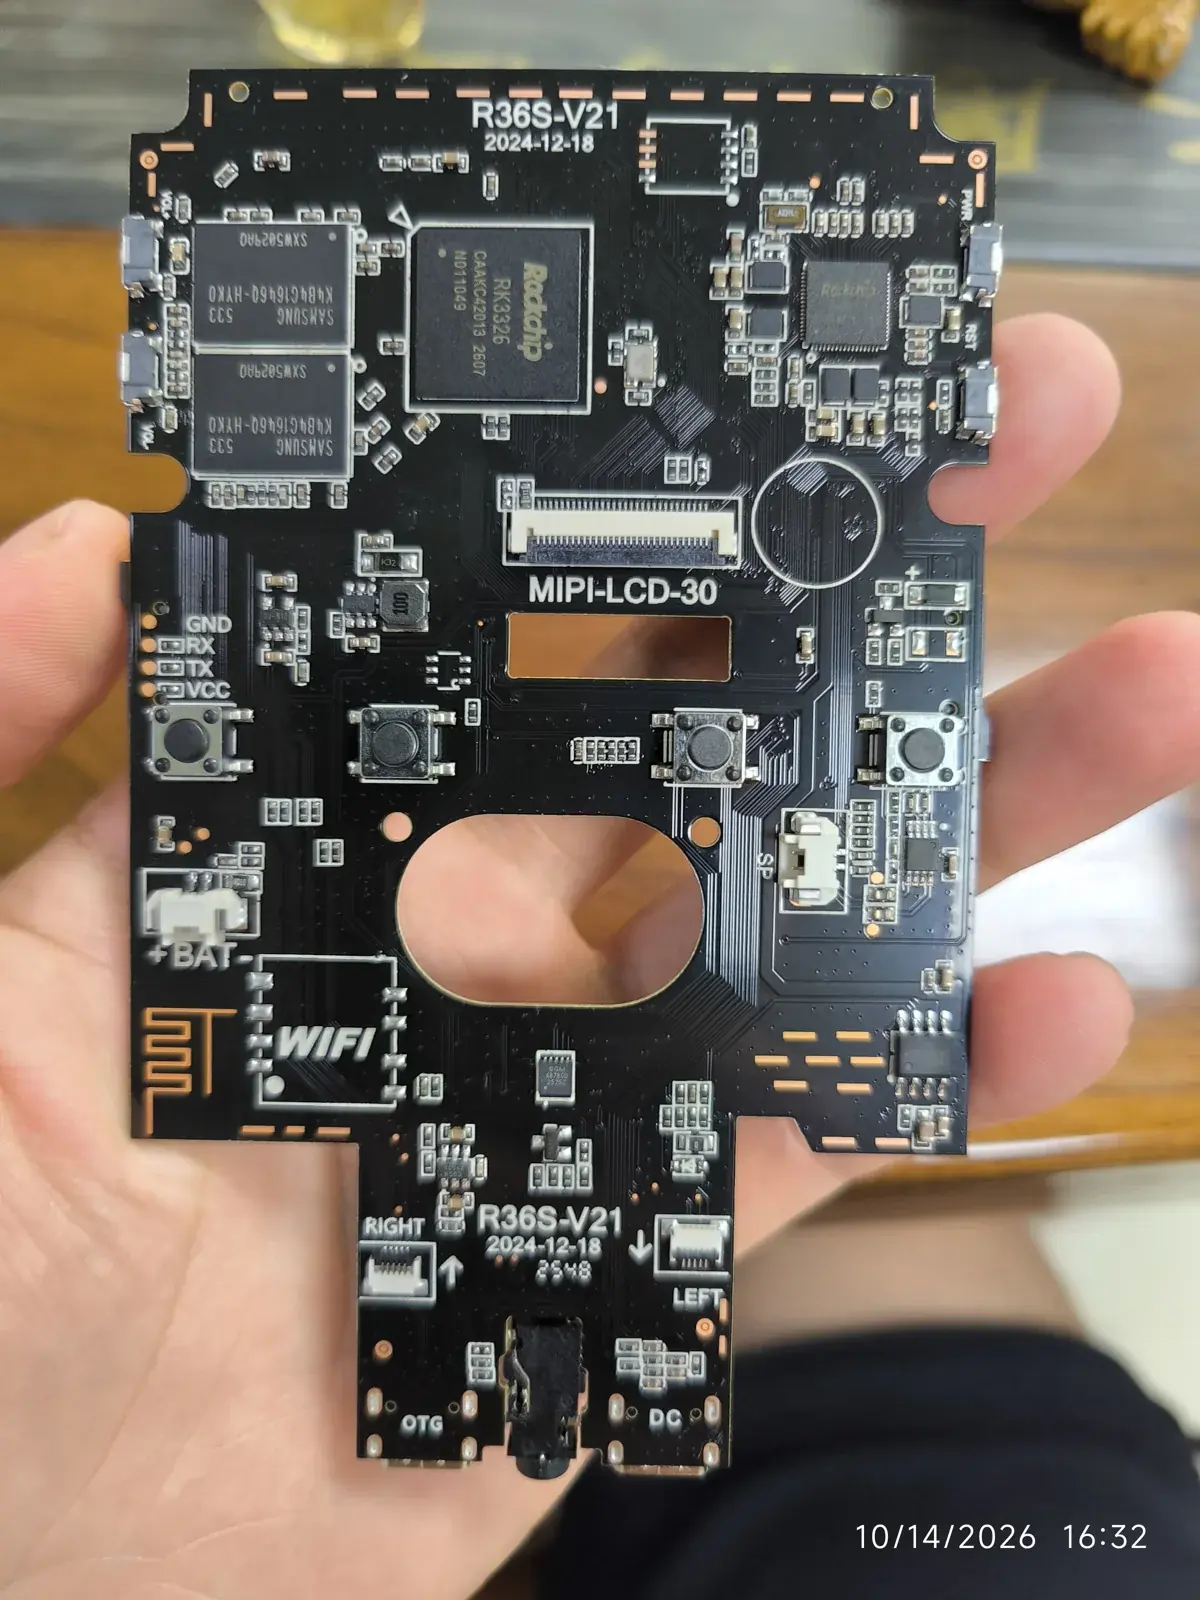 08↗
Productsproducts
An independent R36S handheld shop and technical journal covering board identification, setup, SD cards and save files.
R36SIndependent StoreTechnical Journal
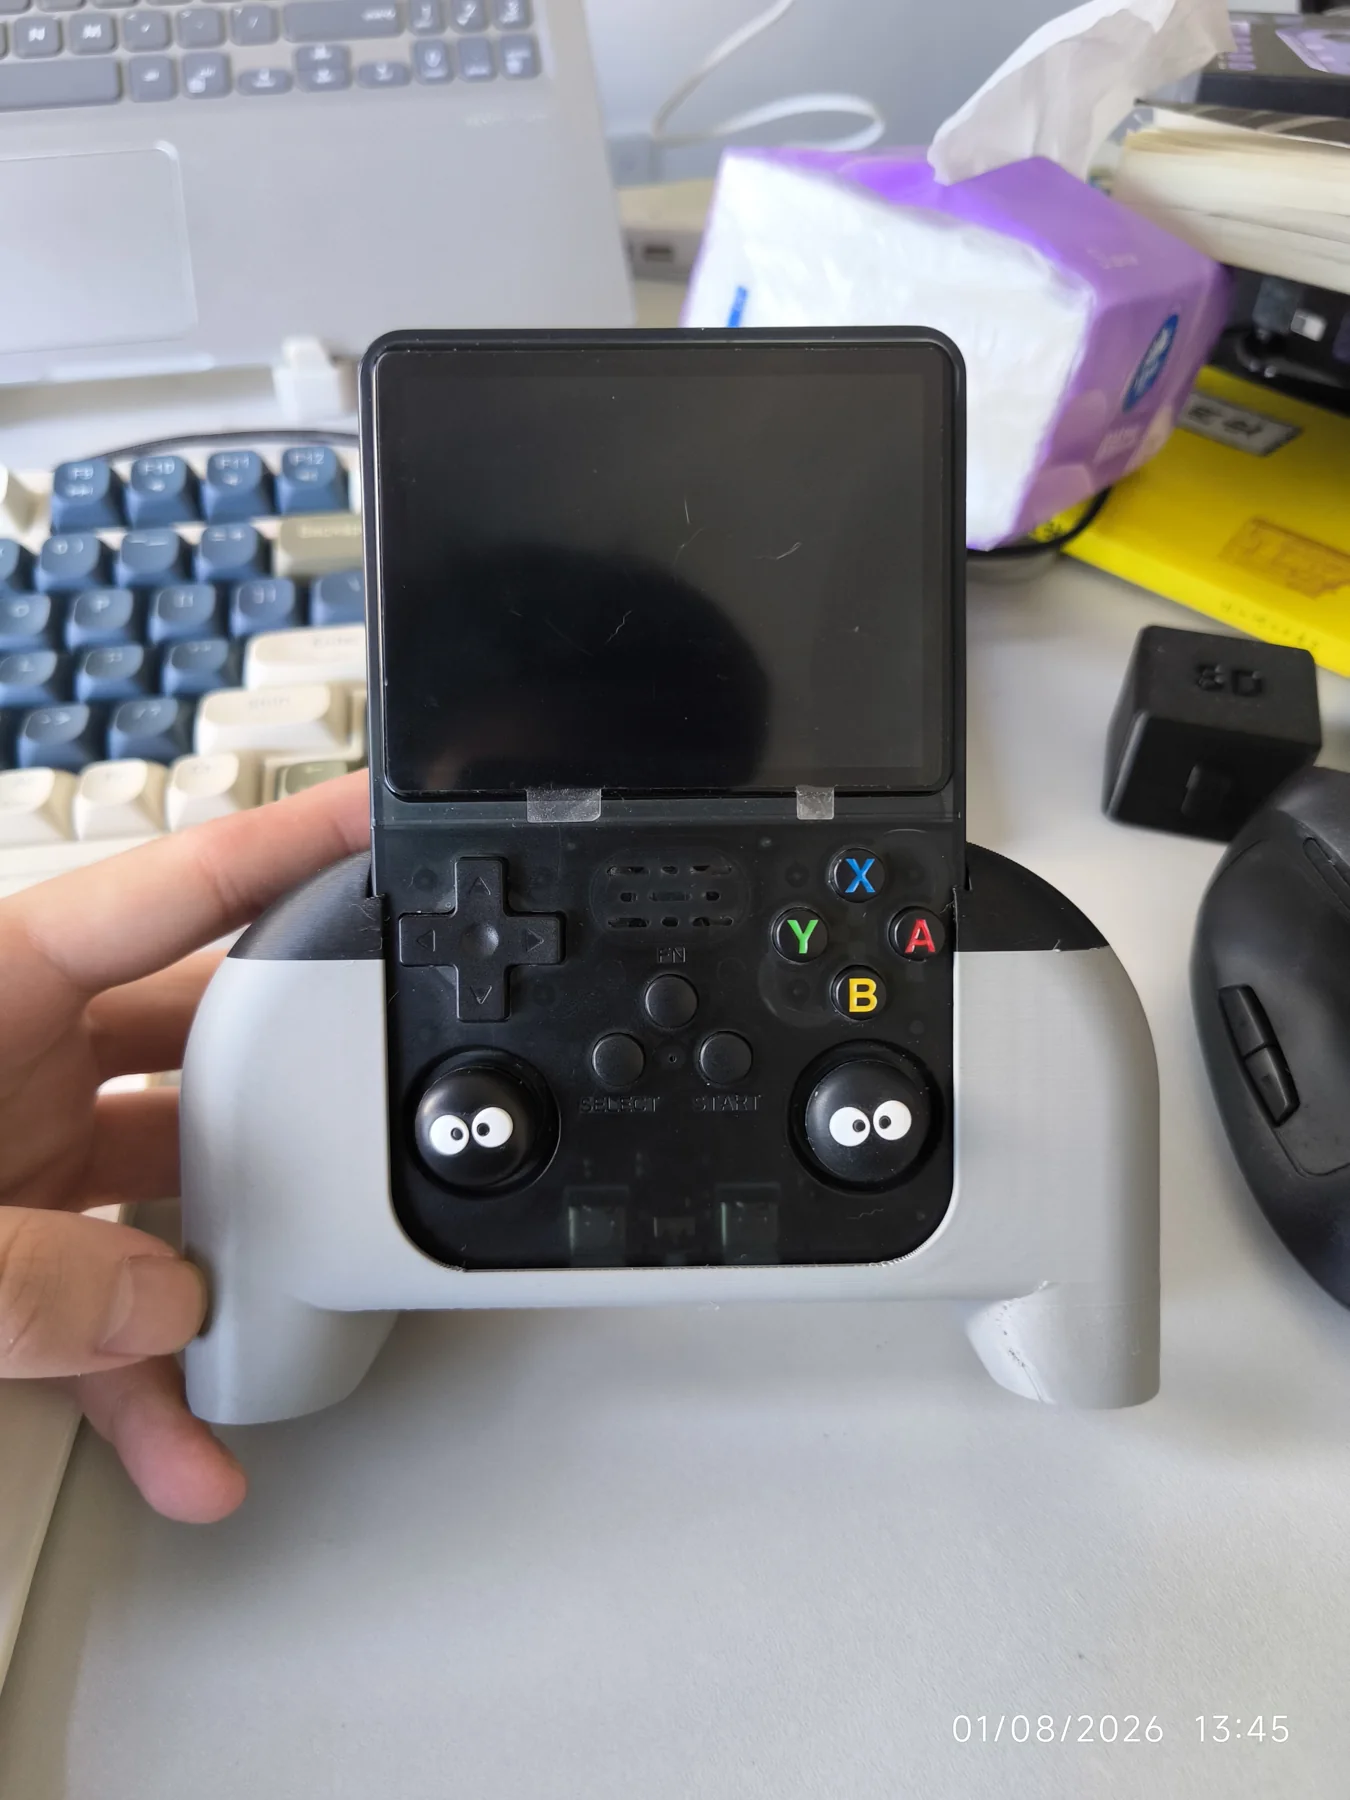 09↗
Experimentsexperiments
Two handhelds, four Linux builds and a 3D-printed grip: taking the R36S and RG353V apart until they feel like machines worth holding.
R36SRG353VROCKNIX
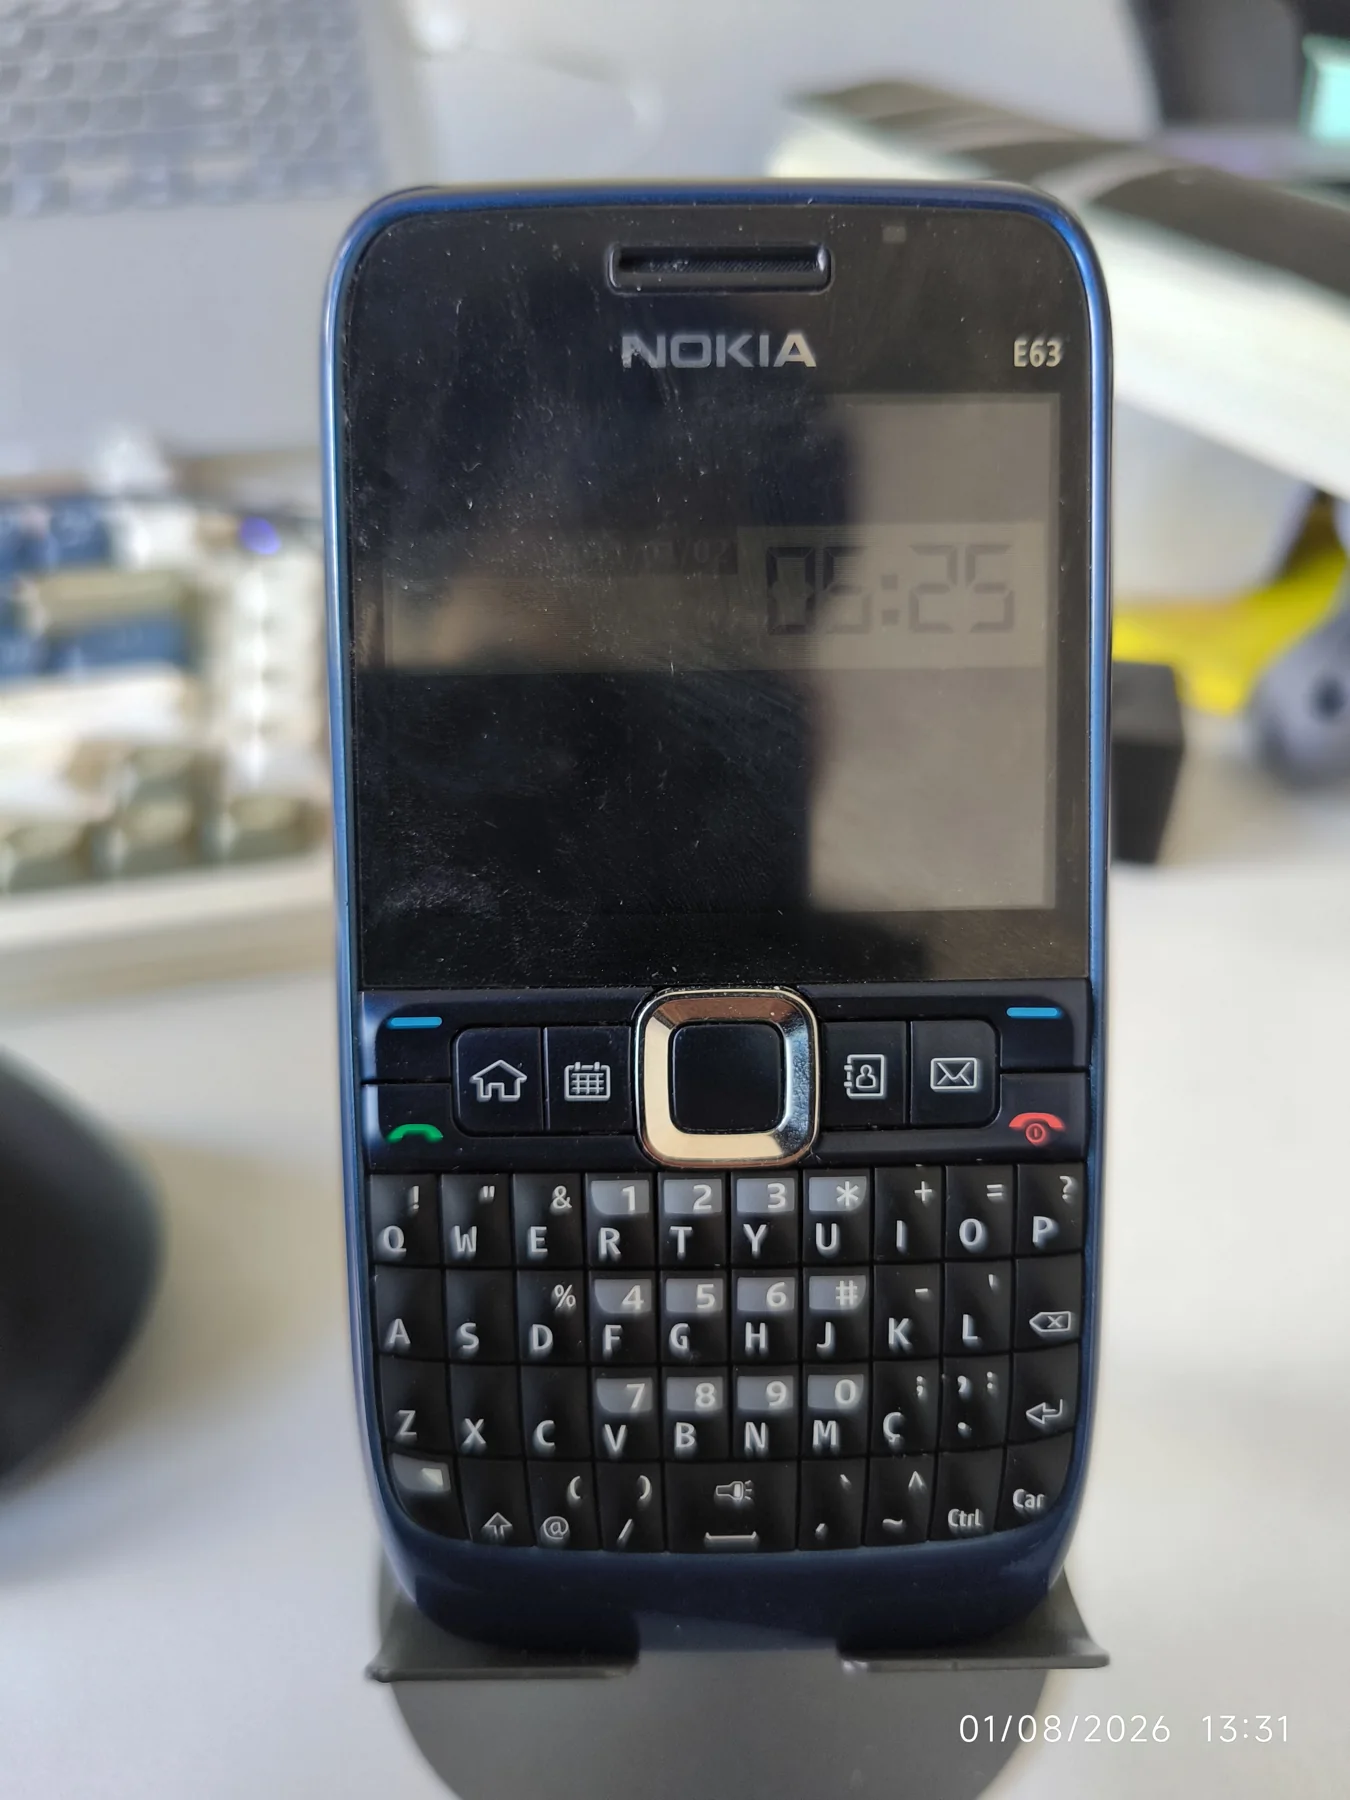 10↗
Experimentsexperiments
A Nokia E63 and E72i back in daily use for TV, music and Bluetooth earphones — hardware from a decade ago that still does the job.
NokiaSymbianRetro Hardware
 11↗
Experimentsexperiments
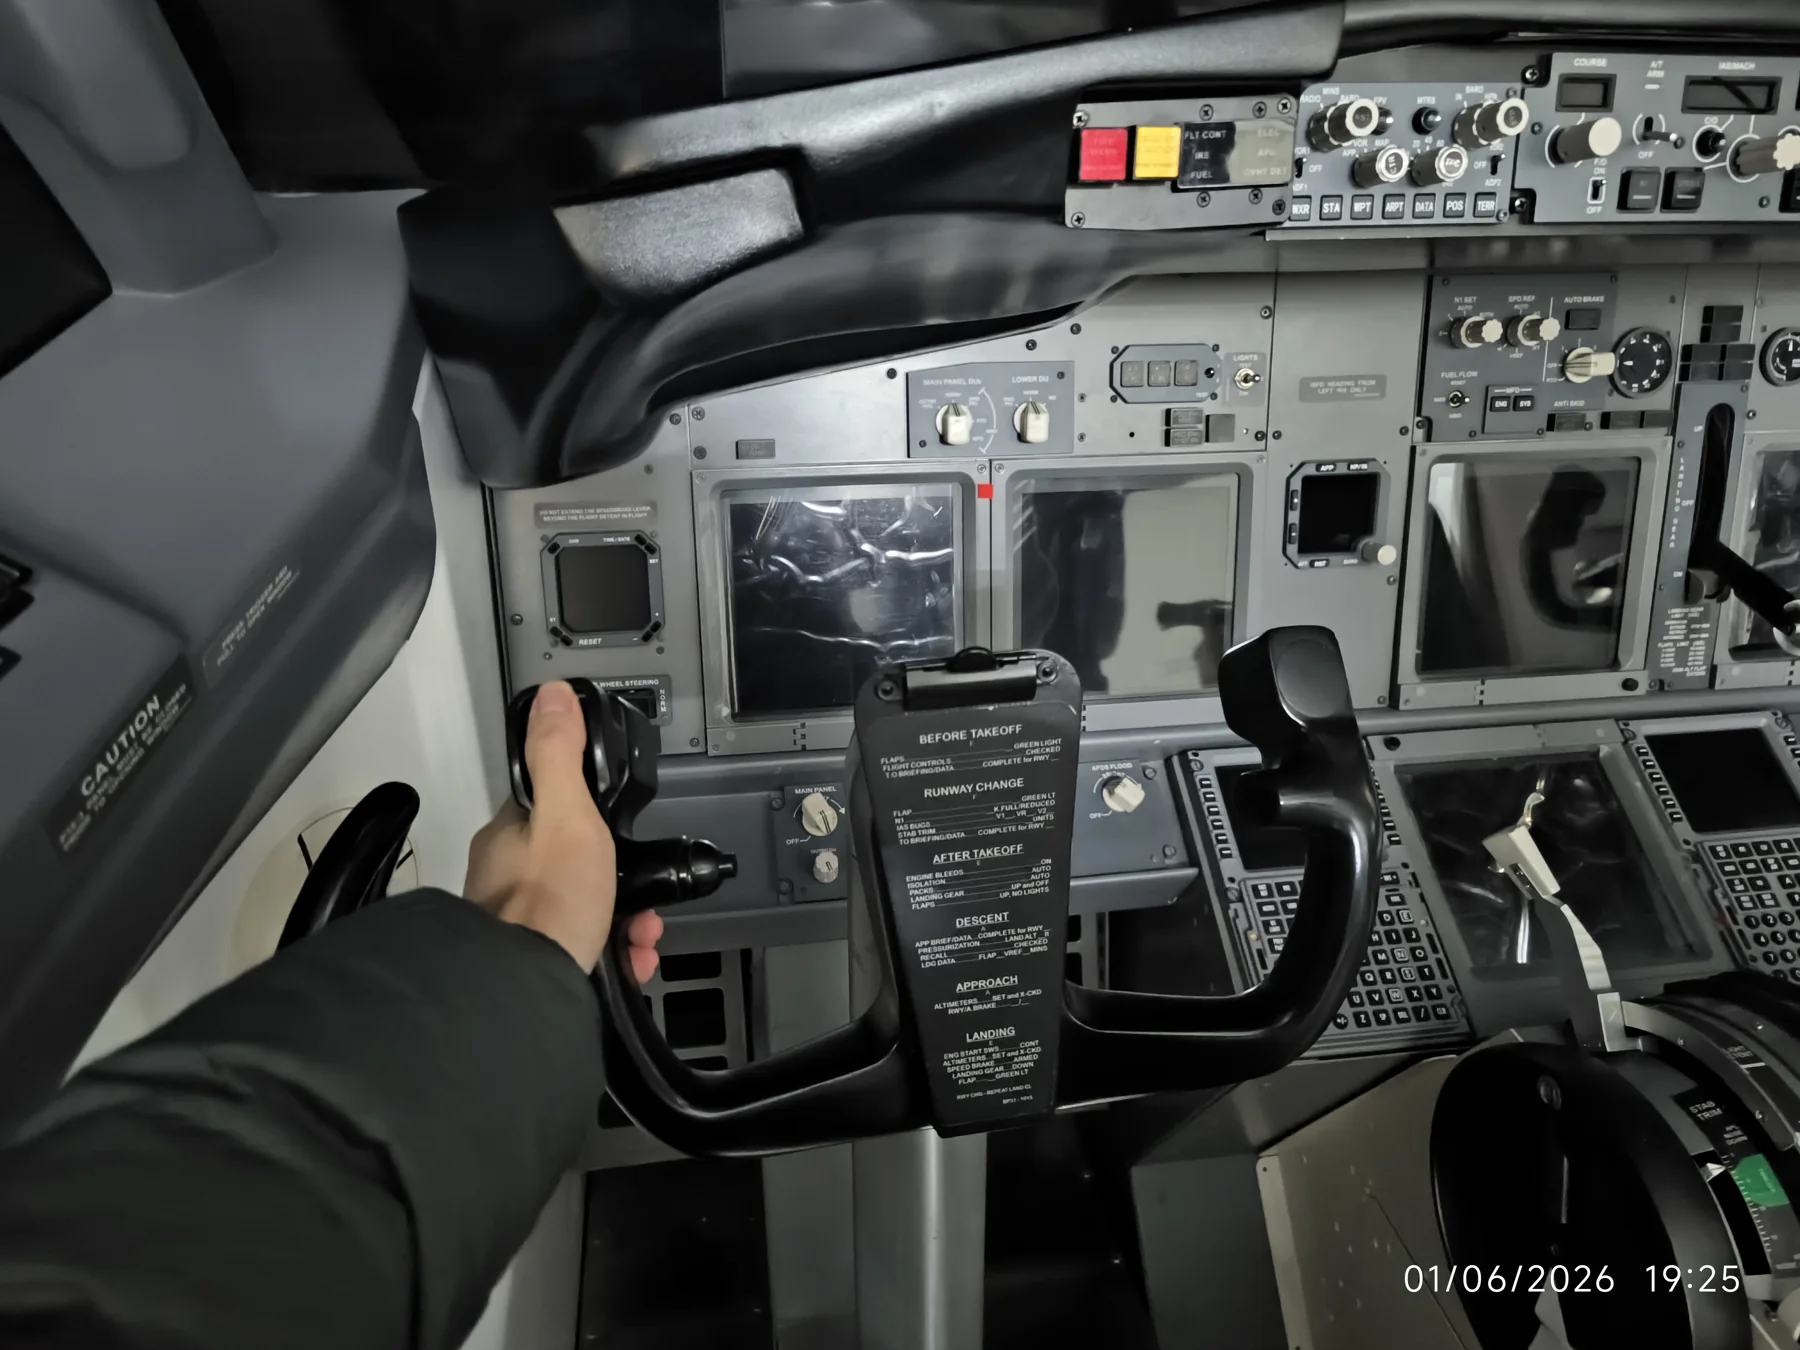
Time in a full-scale simulator cockpit, working through the checklists — plus the carrier models and COMAC keepsakes that keep aviation within reach.
Flight SimulationAviationCOMAC
12↗Roboticsrobotics
A local JARVIS assistant bringing XTTS speech synthesis and Reachy Mini camera and motion controls together.
JARVISReachy MiniXTTS
 13↗
Developer toolstools
A 125B Qwen3.8-Flash-Next running on one RTX 5060 Ti: 16 GB VRAM, 64K context, 74–110 tok/s decode in a real session.
Qwen3.8-Flash-NextStrataLocal Inference
 14↗
Developer toolstools
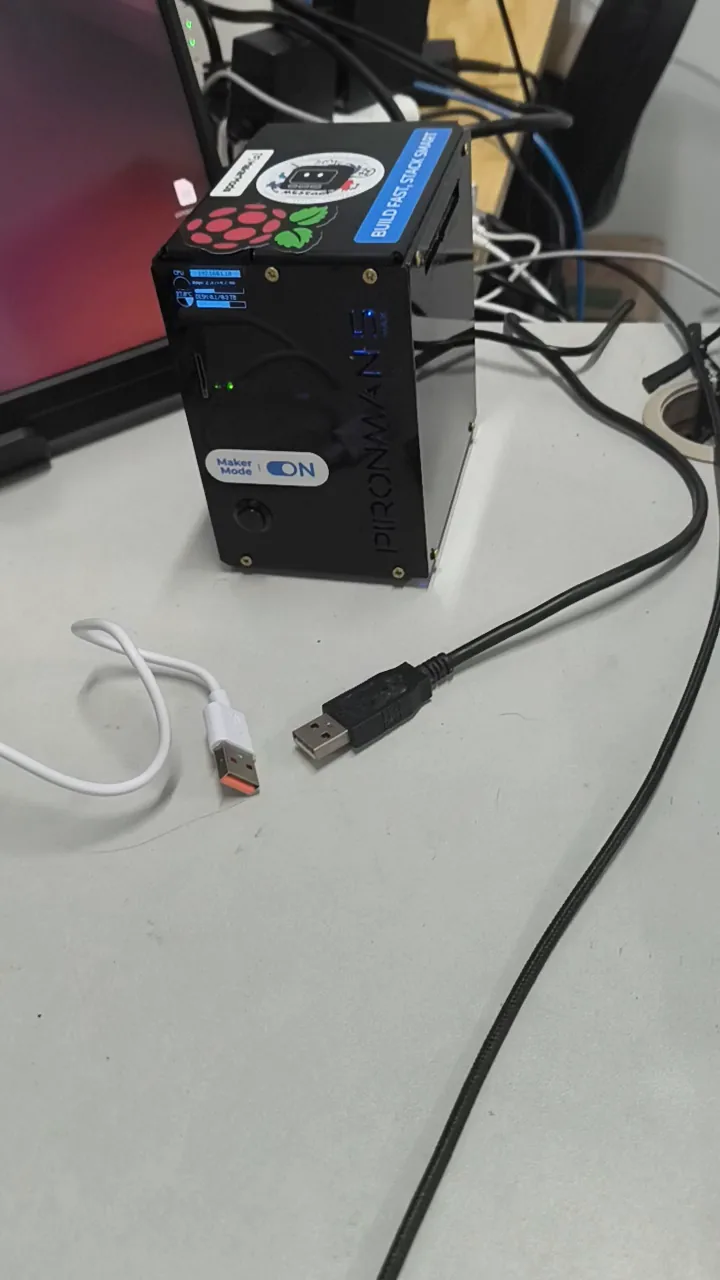
A Raspberry Pi 5 on Ubuntu with an LLM-8850 M.2 accelerator running AXERA's quantized Qwen2.5-0.5B: 18.15–18.42 tok/s across three runs of one prompt, and a model that introduced itself as created by Anthropic.
Qwen2.5-0.5BRaspberry Pi 5LLM-8850
15↗Roboticsrobotics
A local console for AGIBOT G2: a 3D skeleton and joint panel in the browser, and a headset view that pins five camera feeds in space with controller-driven arms.
AGIBOT G2WebXRTeleoperation
16↗Roboticsrobotics
A hands-on LED matrix control experiment on Arduino UNO Q.
Arduino UNO QLED MatrixHardware
 17↗
Developer toolstools
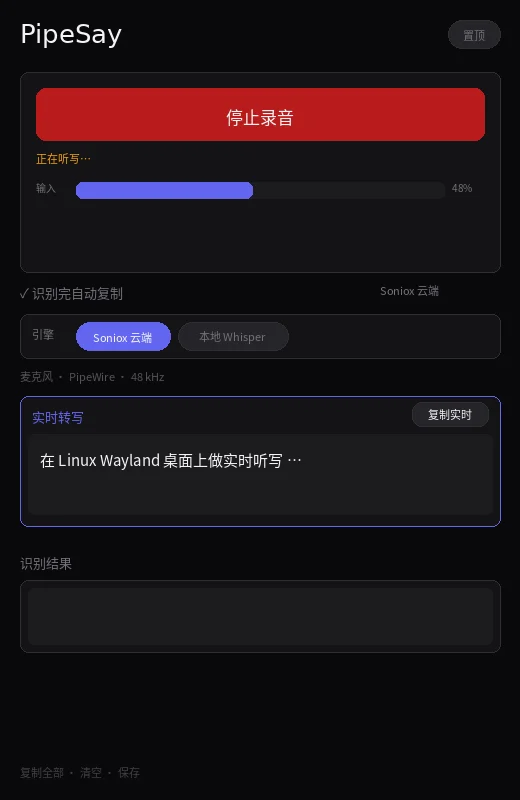
Linux live dictation for Wayland — speak, see text, auto-copy. MIT.
Python