MicroDuck / 牛来
From crouching to hopping: designing rewards that teach a small biped to jump in simulation.
Set the goal and experiment design: defined reward and motion targets, followed simulation training and turned the results into a reproducible record.
The vertical cut with its own burned-in subtitles, running from getting the card recognised and training spin to the remark that nobody seemed to have done jump yet.
A row of MicroDucks stepping on one checkerboard at once, an 8-second loop. No audio.
This project explores PPO reward design and motion stability in a simulation training environment for MicroDuck, an open source robot from Pollen Robotics and Hugging Face. Policies are exported to ONNX. The video shows simulation results, not a claim of real robot validation. Added on 2026-10-31: the Thor training run and a batch of MicroDucks stepping in parallel environments.
Experiments describe their actual environment and scope. Check the linked source for implementation details, license, current support and reproduction steps.
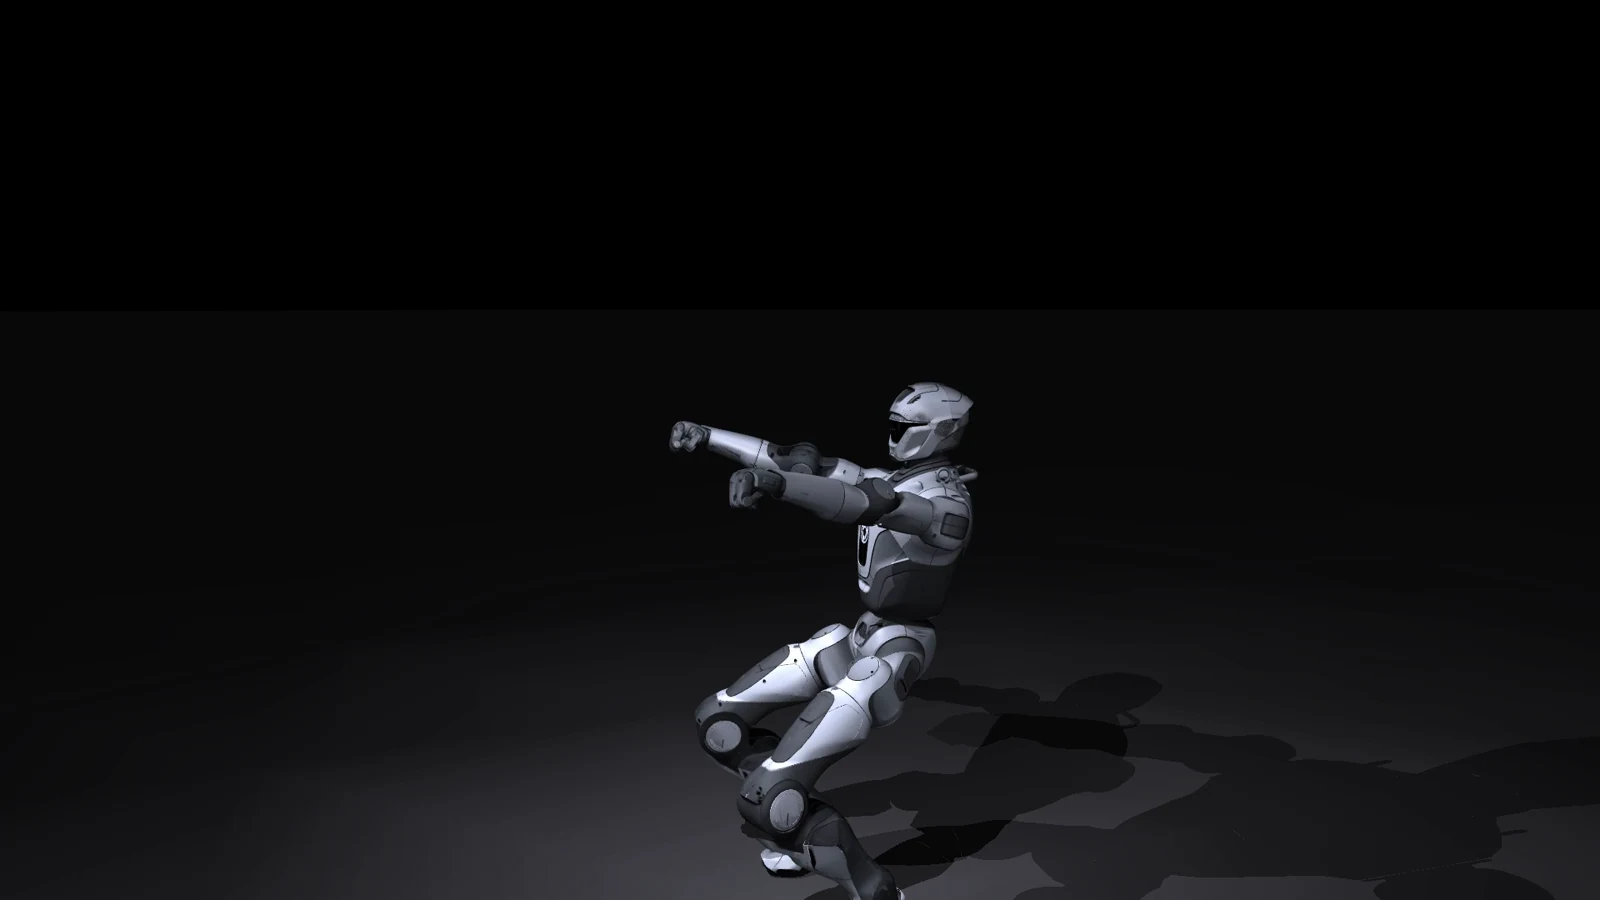 动作重定向 · 仿真
T800 / Backflip Retargeting
Moving G1 backflips from an open motion dataset onto the T800 humanoid: 1.227× leg-length retargeting, per-frame IK correction, and MuJoCo kinematic replay rendered at 50 fps. The RL branch failed to produce a policy.
↗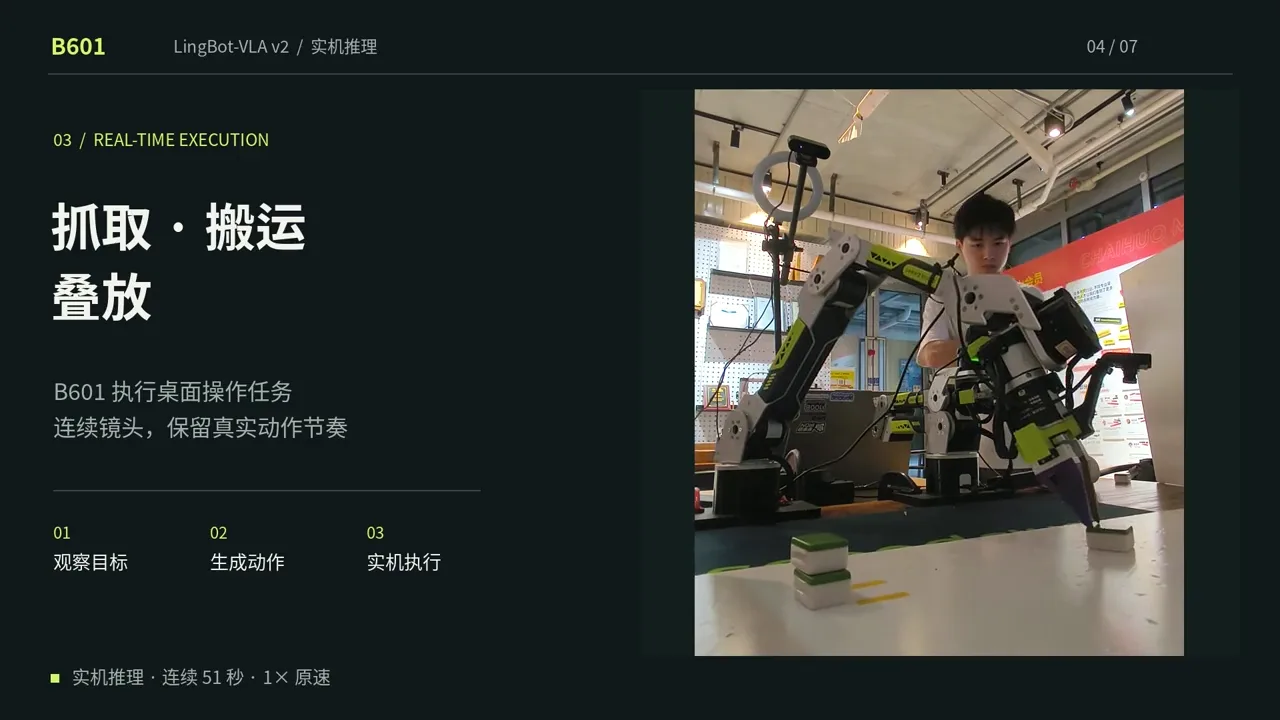 实机推理
B601 × LingBot-VLA v2
Bringing teleoperation demos, VLA inference and real dual arm manipulation together on the B601.
↗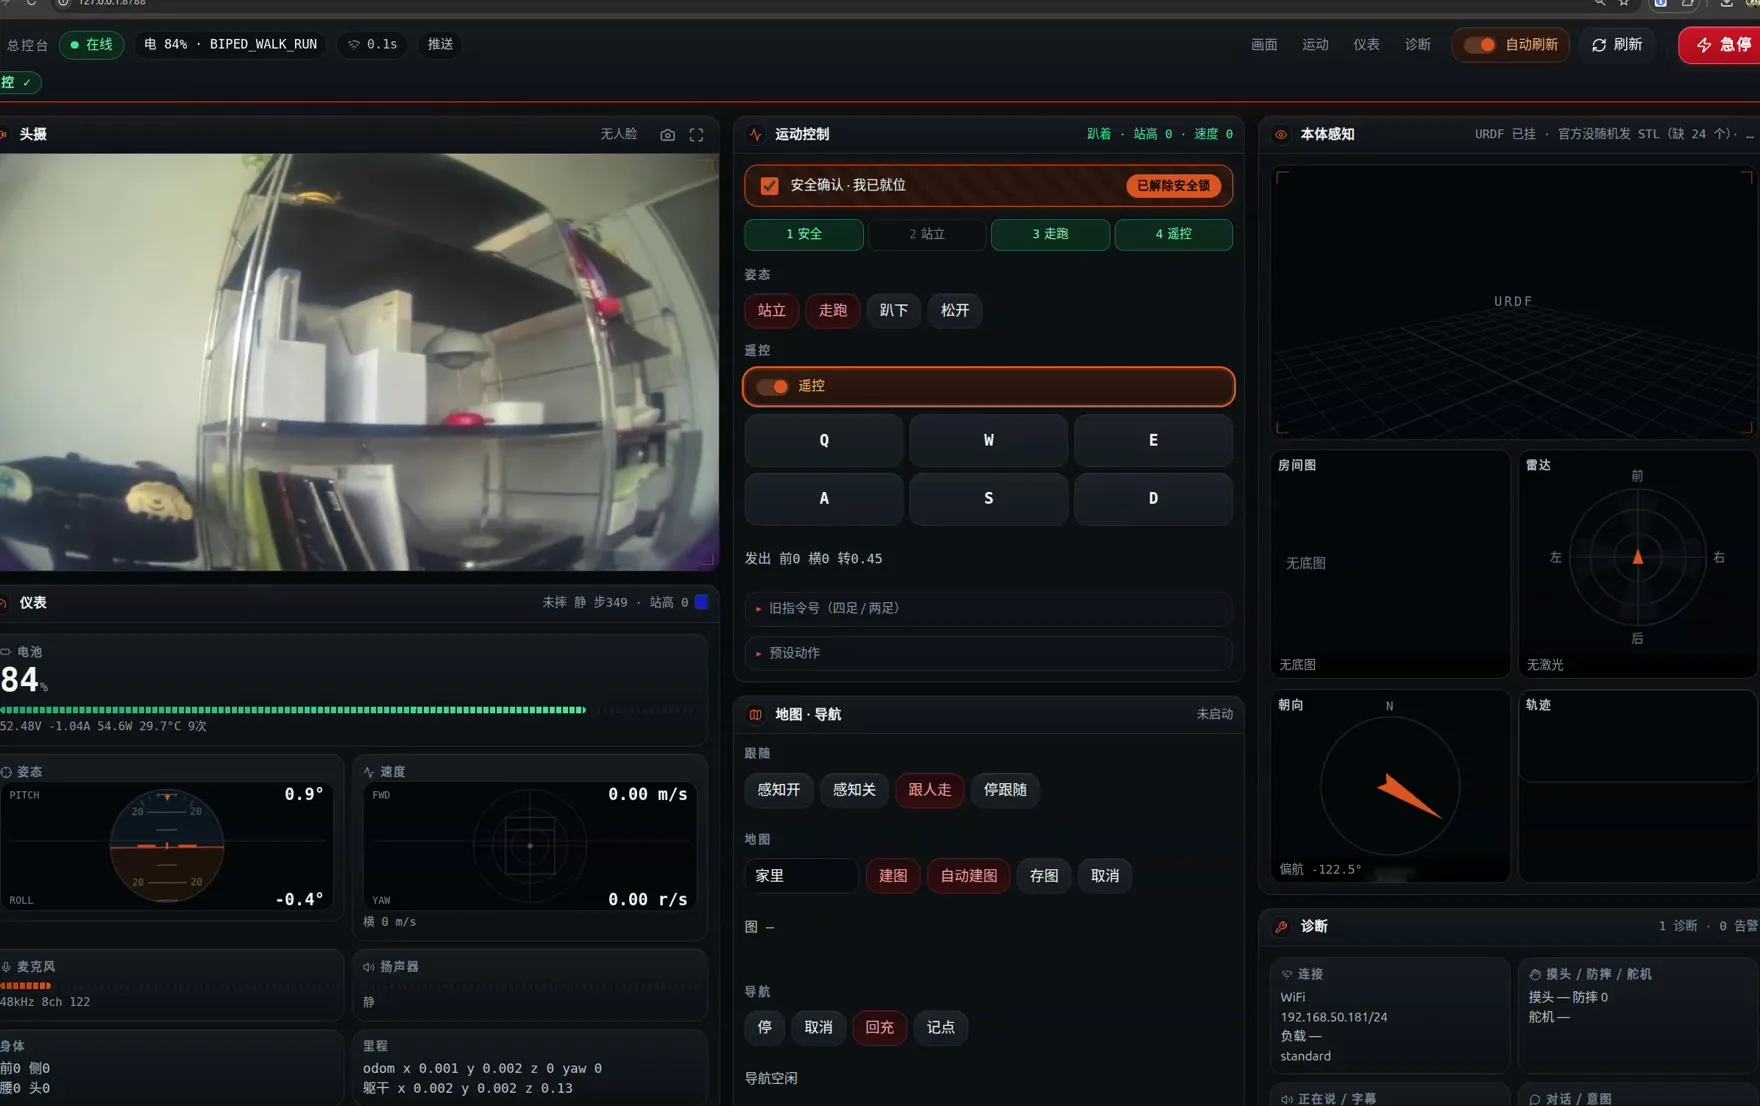 机器人交互
Q1 / Robot Console
The robot's stereo camera, telemetry, voice and motion control in one browser console — operating a Yuan Q1 humanoid in Shanghai from Shenzhen.
↗