JARVIS / Reachy Mini
A local JARVIS assistant bringing XTTS speech synthesis and Reachy Mini camera and motion controls together.
Designed the integration and debugged it: wired the local assistant, speech synthesis and the robot's camera and motion APIs, testing latency and motion timing.
JARVIS brings local speech recognition, XTTS synthesis and Reachy Mini camera and motion controls into a visible workspace. The RTX Spark setup runs local model and ComfyUI workflows; a separate local deployment tests XTTS voice synthesis on an RTX 5060 Ti system. The demo shows the console with real Reachy Mini camera footage. It documents a system integration experiment, not general robot autonomy.
Experiments describe their actual environment and scope. Check the linked source for implementation details, license, current support and reproduction steps.
 本地模型 · RTX 5060 Ti
Strata / Qwen3.8-Flash-Next
A 125B Qwen3.8-Flash-Next running on one RTX 5060 Ti: 16 GB VRAM, 64K context, 74–110 tok/s decode in a real session.
↗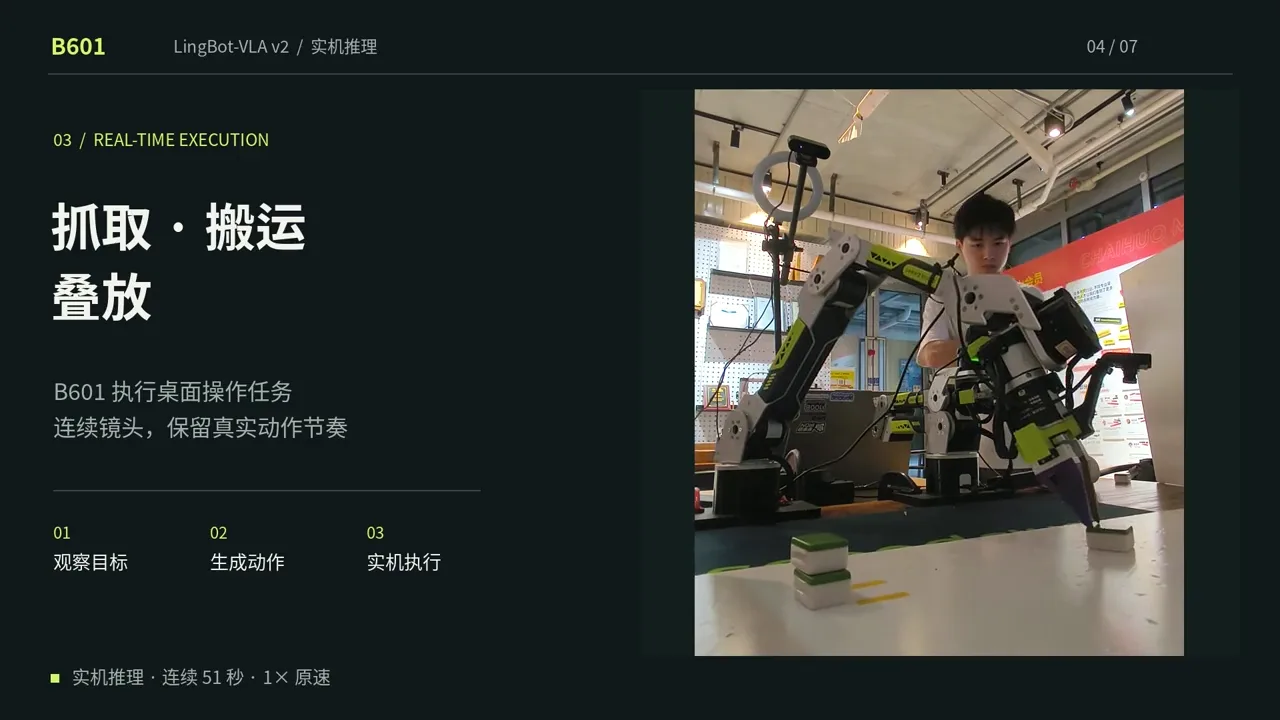 实机推理
B601 × LingBot-VLA v2
Bringing teleoperation demos, VLA inference and real dual arm manipulation together on the B601.
↗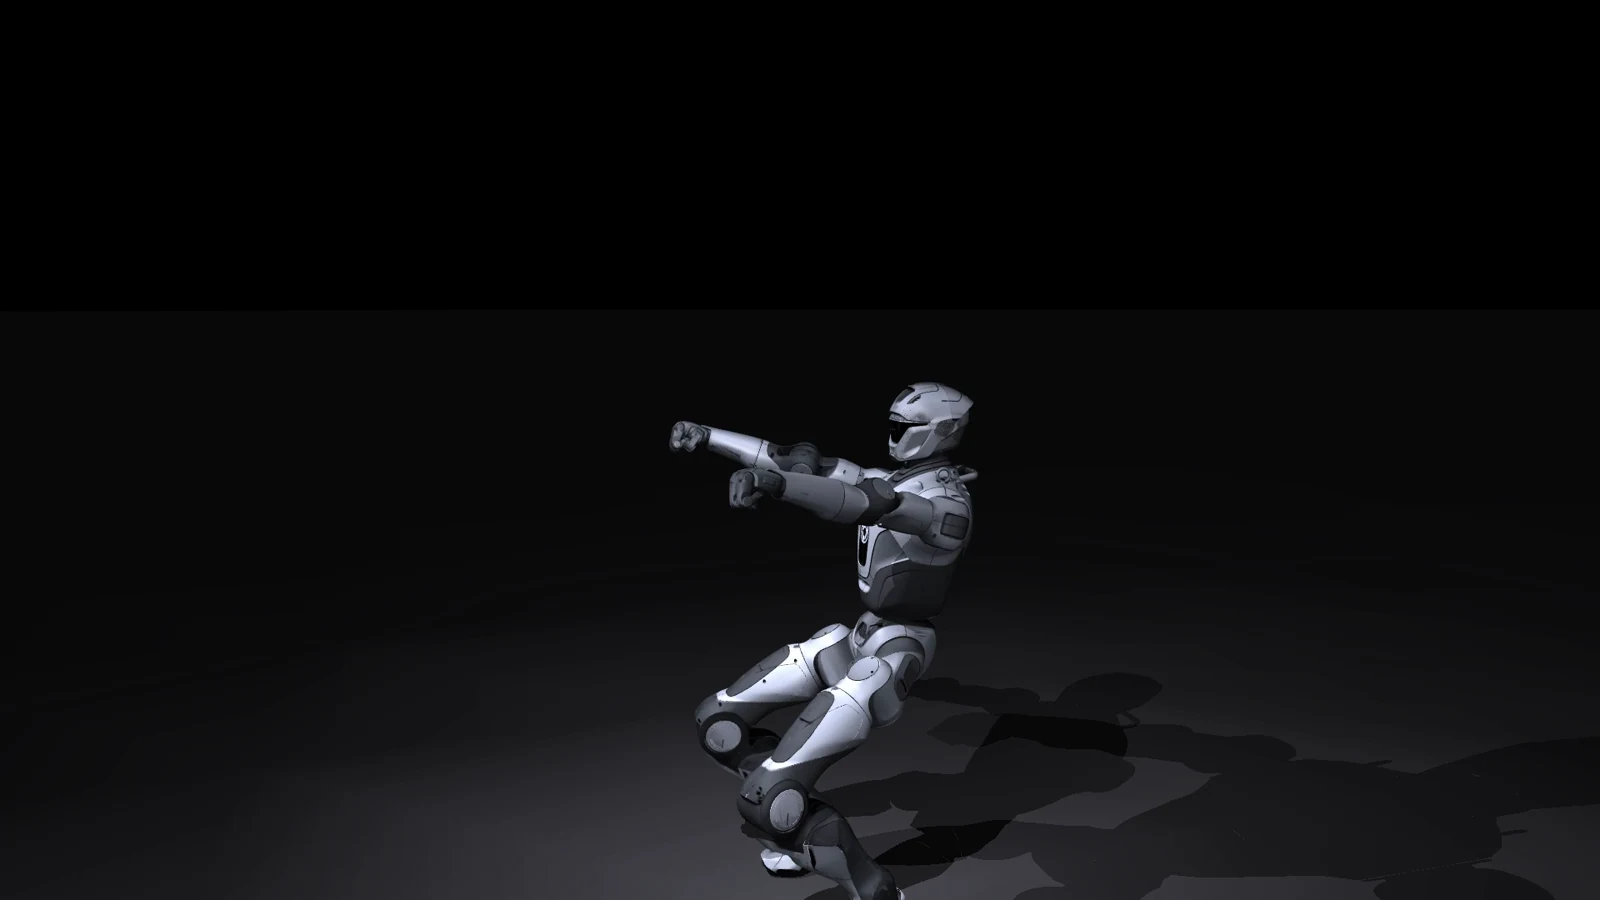 动作重定向 · 仿真
T800 / Backflip Retargeting
Moving G1 backflips from an open motion dataset onto the T800 humanoid: 1.227× leg-length retargeting, per-frame IK correction, and MuJoCo kinematic replay rendered at 50 fps. The RL branch failed to produce a policy.
↗